Projects
GitHubOpen-source tools I build for robot learning, simulation and Rust.
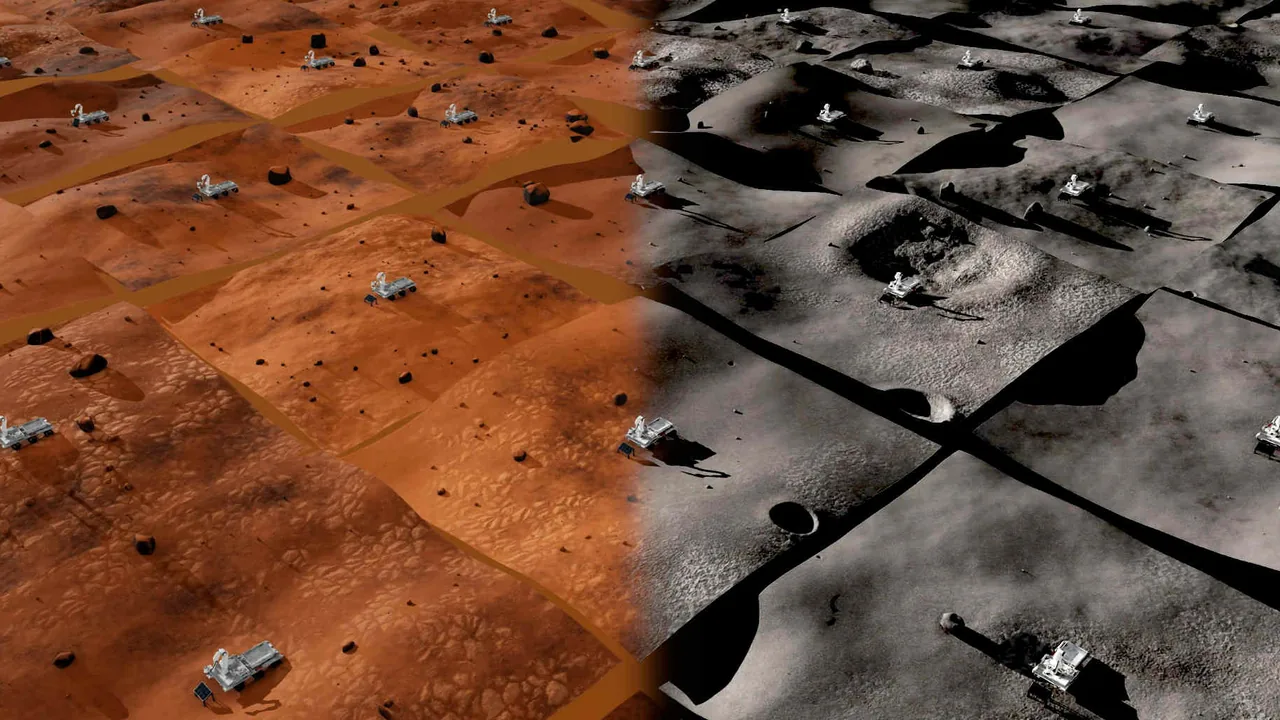
Space Robotics Bench
Simulation framework and benchmark for robot learning in space, built on NVIDIA Isaac Sim.
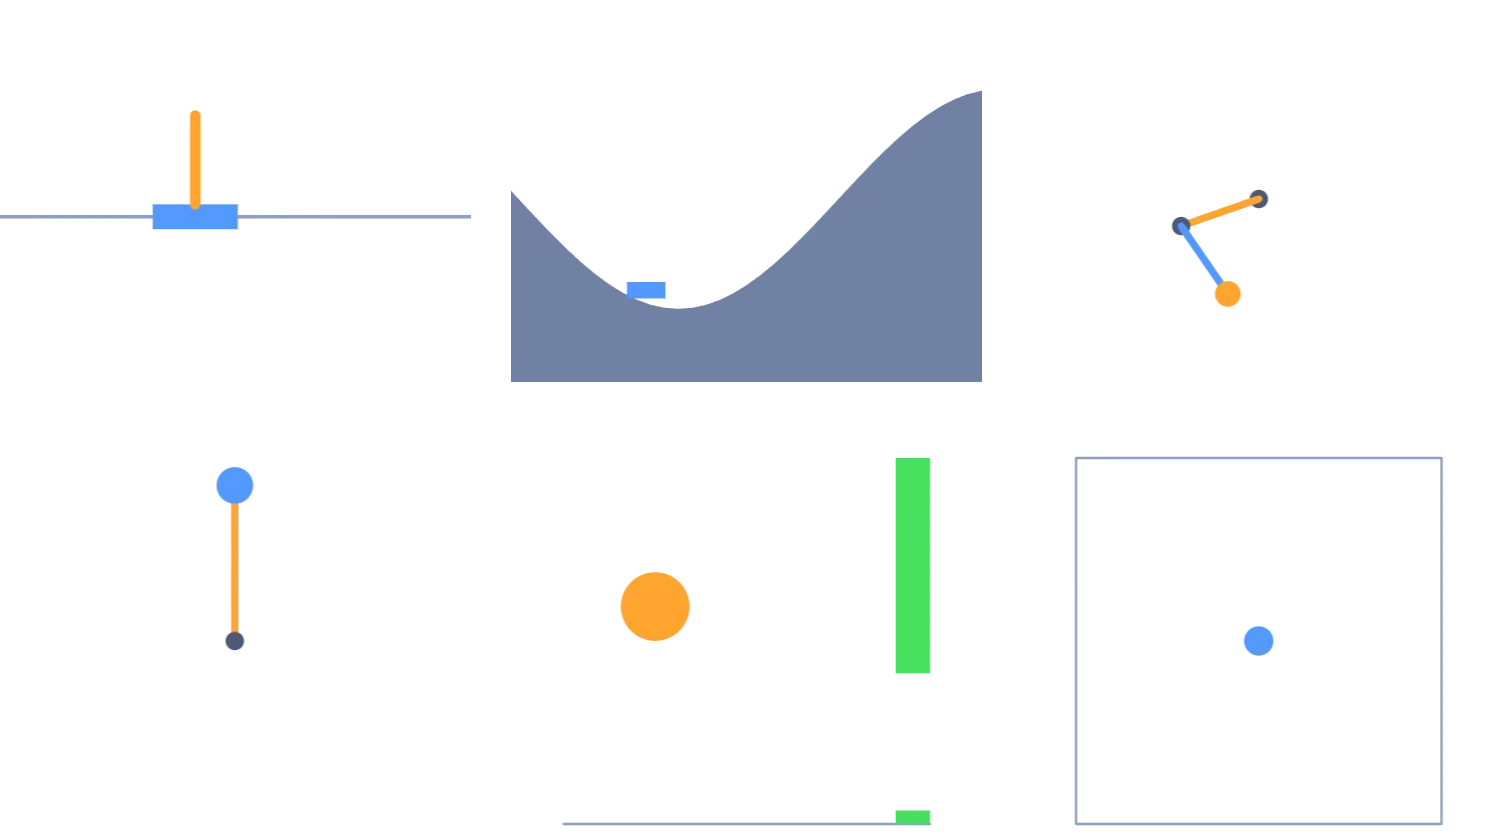
gymnasium_rs
Gymnasium environments in Rust, running in the browser via WebAssembly.
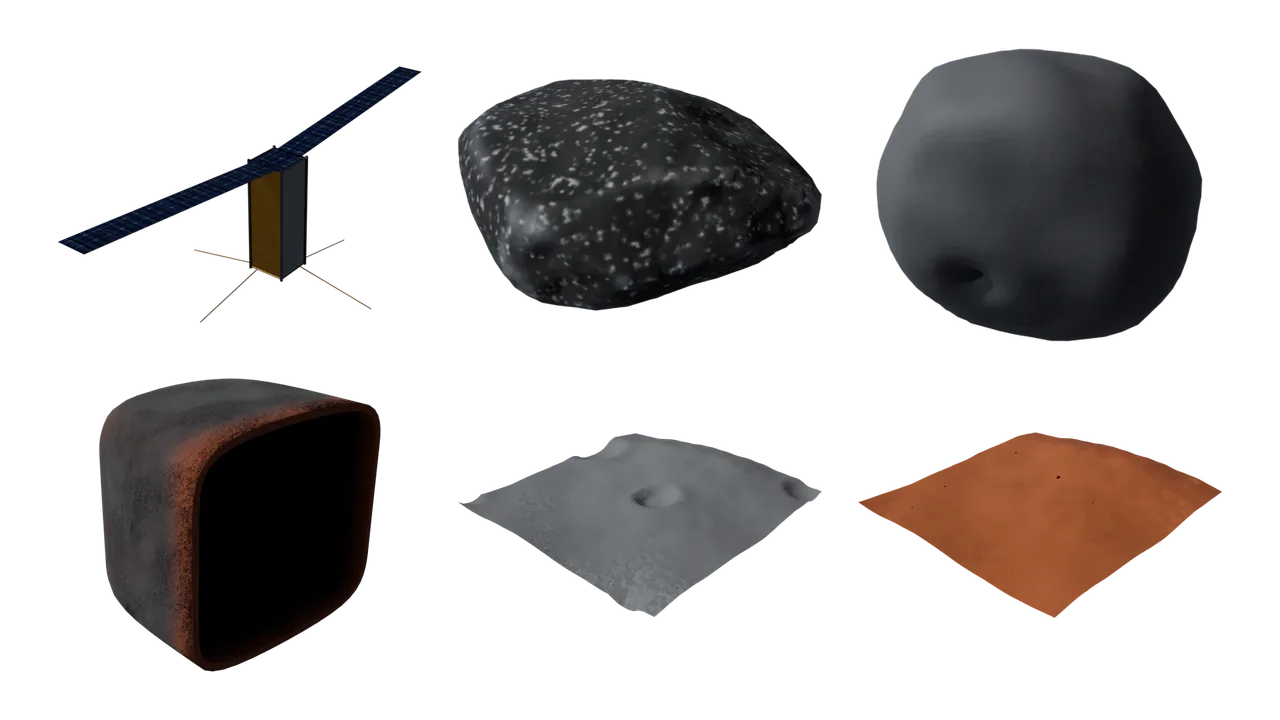
SimForge
Framework for diverse virtual environments through procedural generation of simulation assets.
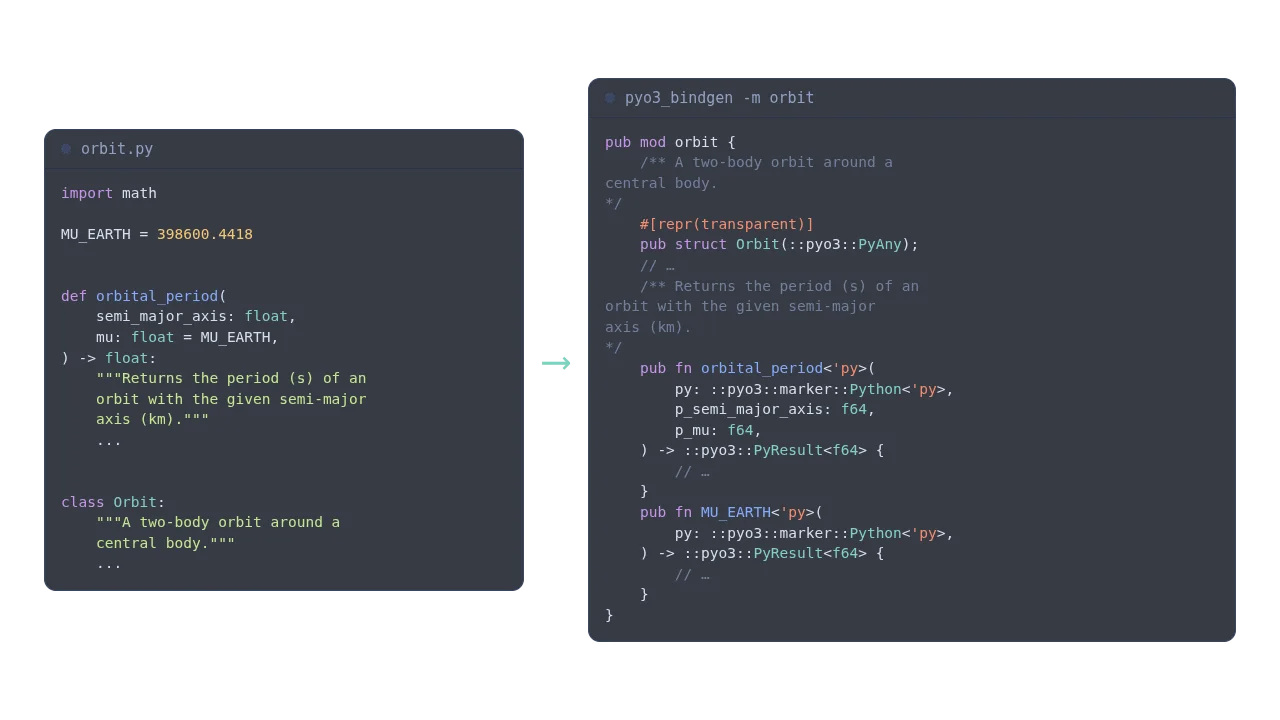
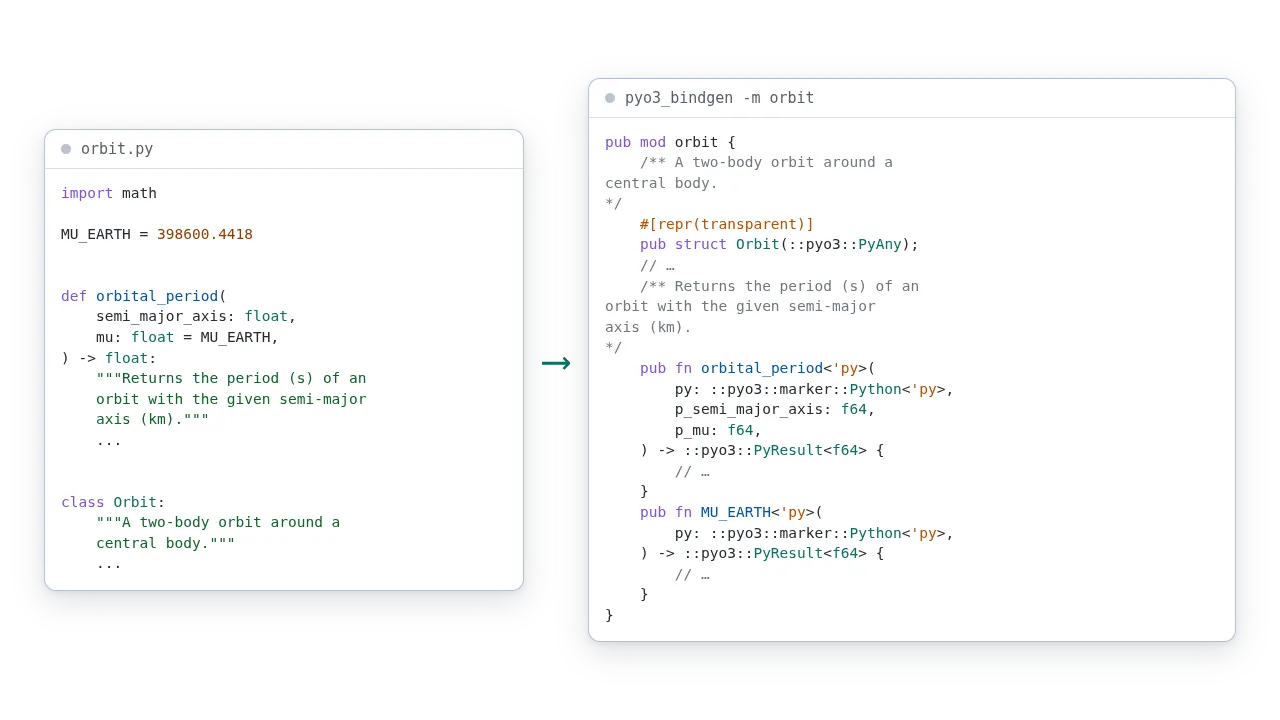
pyo3_bindgen
Automatic generation of Rust FFI bindings to Python modules via PyO3.
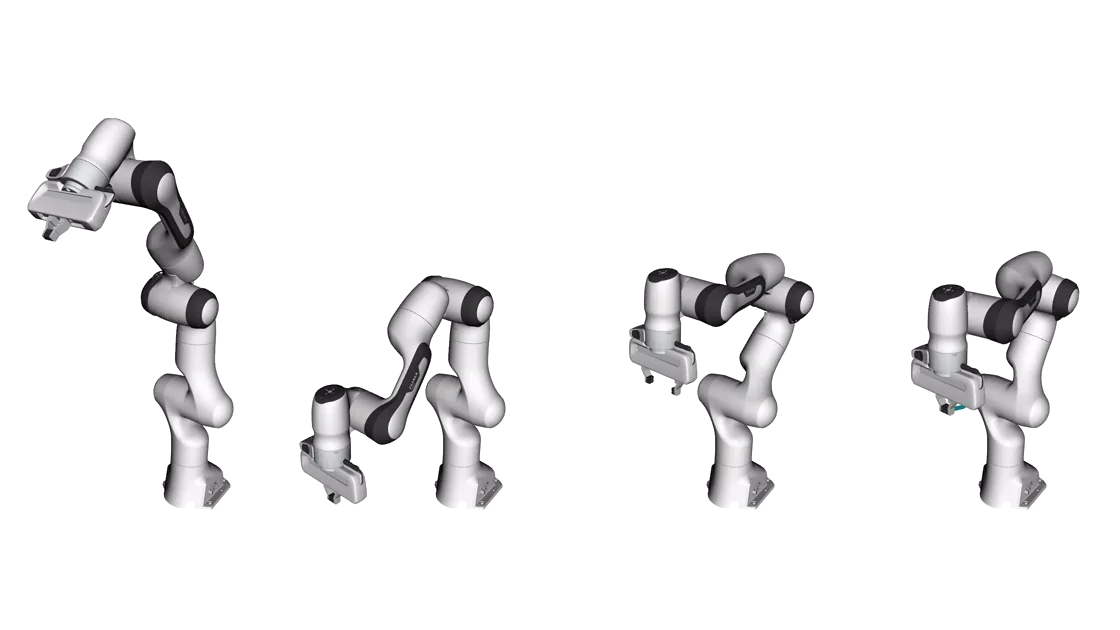
pymoveit2
Python interface for MoveIt 2 that plans and executes robot motion over ROS 2.
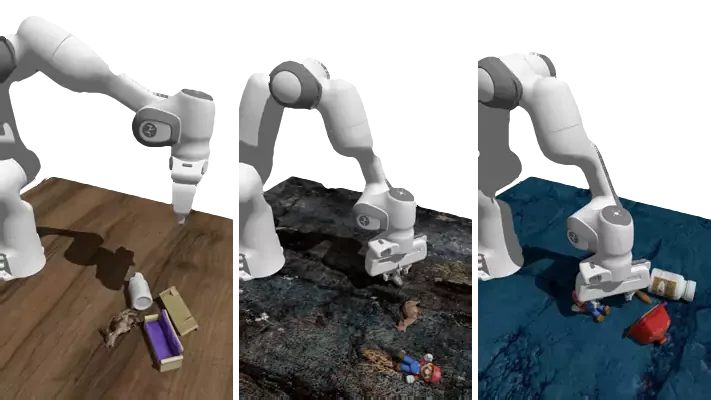
drl_grasping
Deep reinforcement learning for robotic grasping from 3D octree observations.