pymoveit2
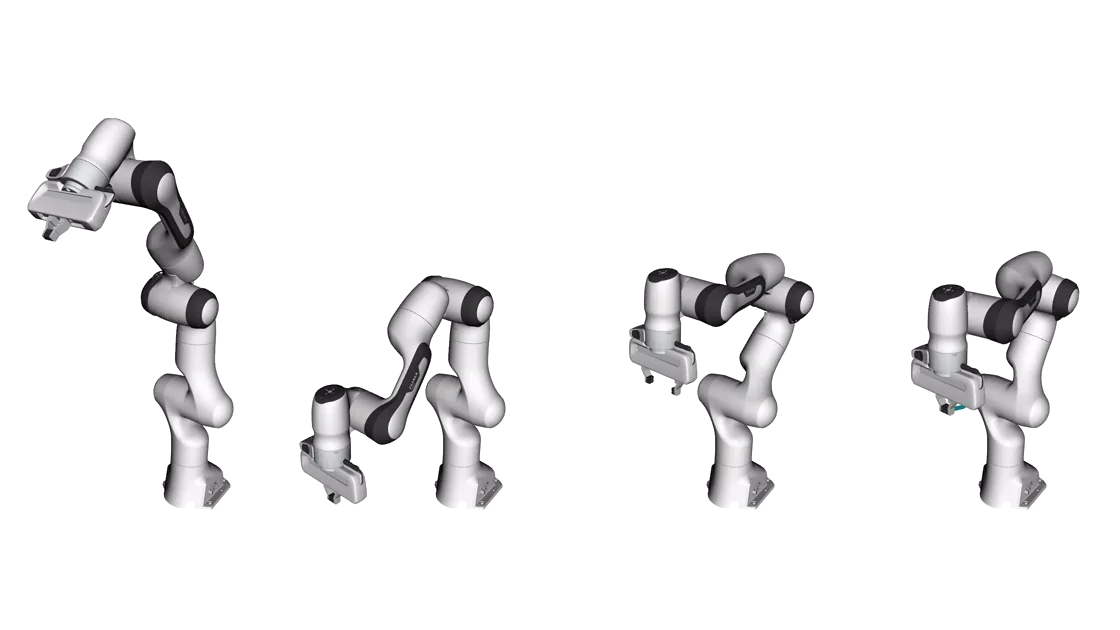
Python interface to MoveIt 2 for robot motion. pymoveit2 moves a robot from Python by communicating with MoveIt 2 over ROS 2 actions and services. It needs no compiled MoveIt bindings and works with any robot that has a MoveIt 2 configuration. It is used across the ROS 2 community, including in the robot arm labs I teach. The latest release is pymoveit2 5.0.0 (September 2026), licensed under BSD-3-Clause. It ships as a ROS 2 package for Humble, Jazzy, Lyrical and Rolling, as a PyPI package and as a Docker image. Features
with connect() as robot: discovers the robot description and sets up the arm, gripper and servo interfaces; ex_doctor.py helps diagnose a setup where nothing moves. Status
Links