Simulation and benchmark for space robot learning on NVIDIA Isaac Sim.
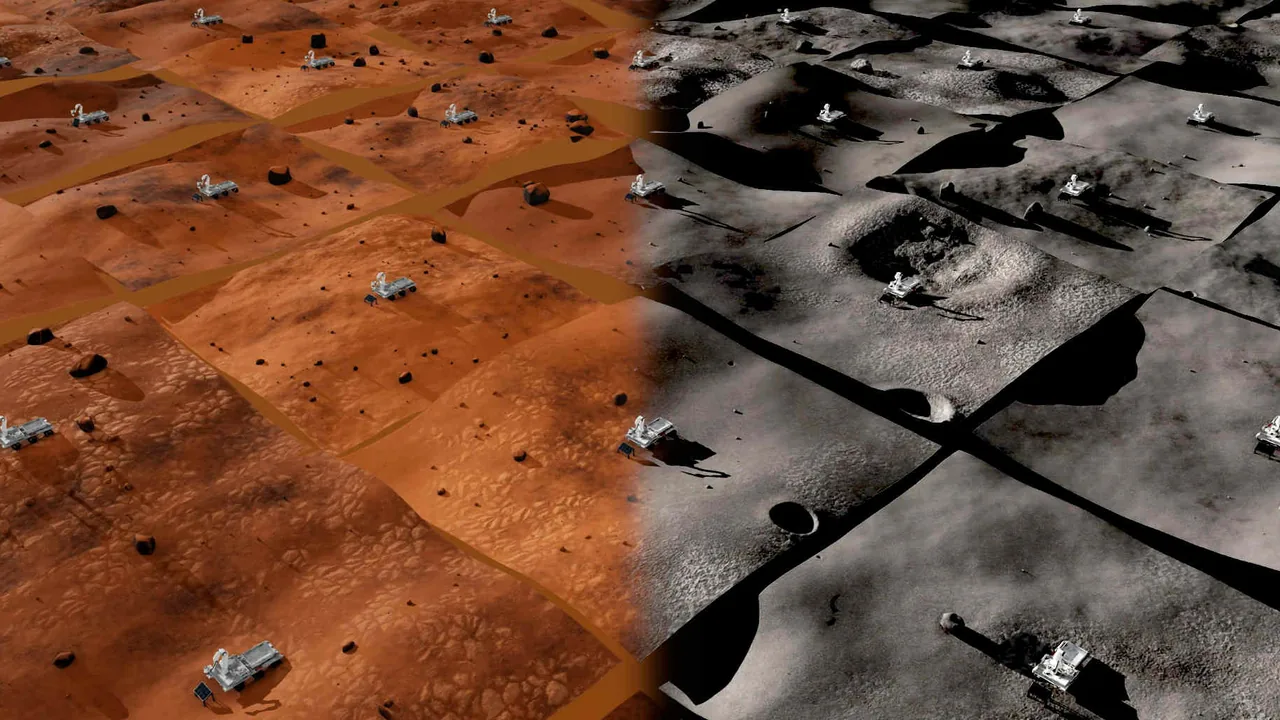
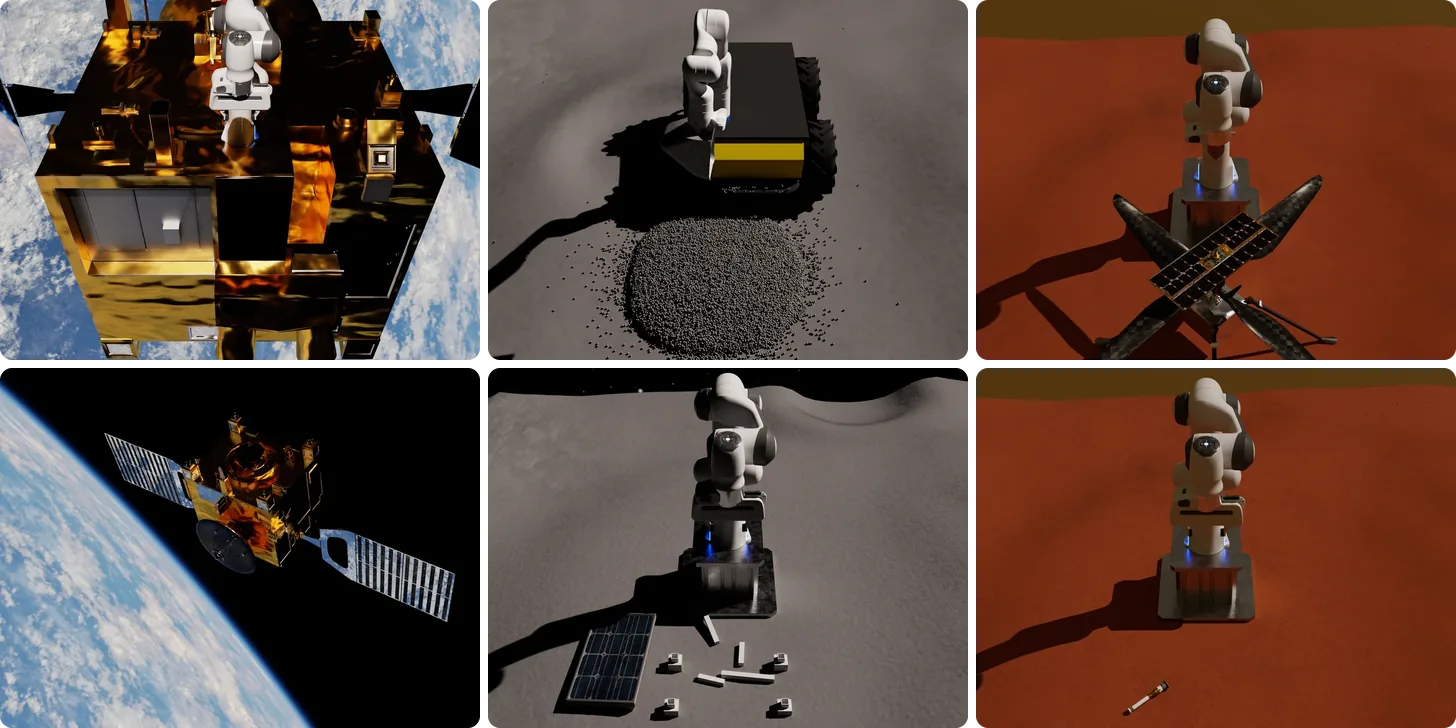
Space Robotics Bench (SRB) is an open-source collection of simulation environments and tasks for robotics research in space, from orbit to the surfaces of the Moon and Mars. Built on NVIDIA Isaac Sim, it trains and evaluates policies across many procedurally varied worlds instead of one.Tasks in orbit, on the Moon and on Mars, one column each: debris capture and mobile debris capture, excavation and solar-panel assembly, screwdriving and sample collection.
Features
Parallel simulation: many environment instances run in parallel to accelerate learning and evaluation.
Procedural generation: terrains, rocks and other assets are generated on demand with SimForge.
Domain randomization: extensive randomization of the simulated scenes for robustness and generalization.
Gymnasium API: environments plug into standard reinforcement-learning frameworks.
ROS 2 interface: interoperates with the ROS 2 and Space ROS ecosystems.
Tasks: manipulation, mobile robotics and mobile manipulation, each with interchangeable robots and space domains.
Status
The latest release is Space Robotics Bench 0.1.0 (October 2026), dual-licensed under MIT or Apache 2.0. Its own assets and those generated with SimForge are released under CC0 1.0.