Research
My research lies at the intersection of Robotics and Machine Learning, with a focus on enabling autonomous systems to learn complex behaviors in unstructured environments.
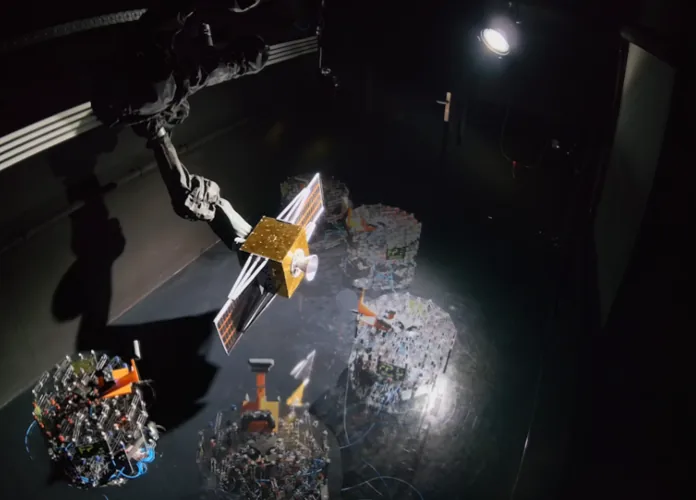
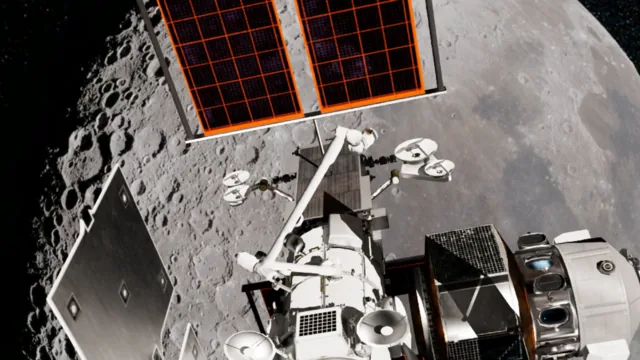
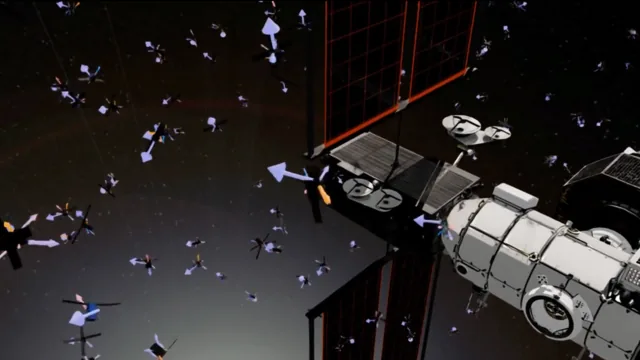
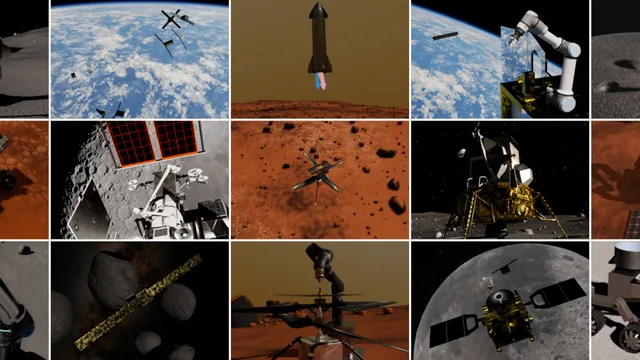
- Space Robotics: Autonomous manipulation and mobility for in-orbit servicing and planetary exploration, including contact-rich assembly, regolith excavation, and navigation on granular terrain
- Reinforcement Learning: Model-based, model-free, and continual methods for adaptive control, with emphasis on sample efficiency and reward-free adaptation to changing conditions
- Modeling and Simulation: Procedural scene generation, domain randomization, and high-fidelity physics for sim-to-real transfer
Publications
2026 5 publications
2025 8 publications
PhD Thesis University of Luxembourg
Robot Learning Beyond Earth: Enabling Adaptive Autonomy in Space
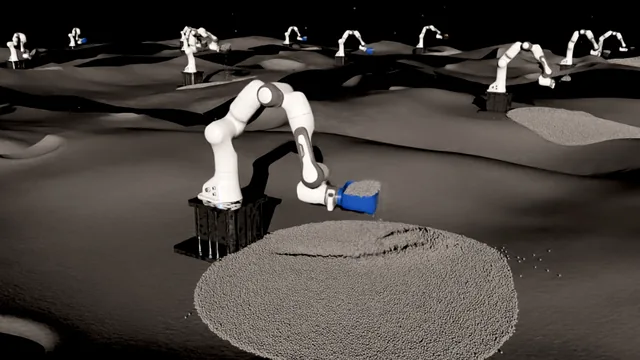
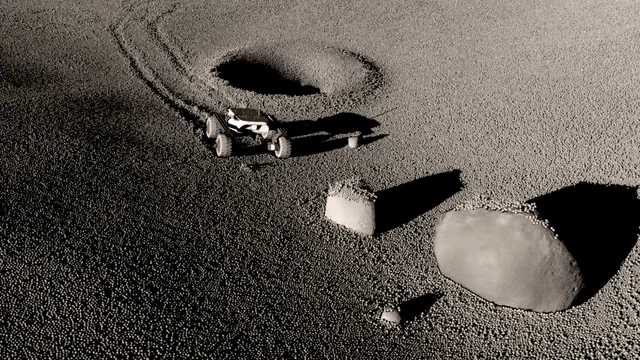
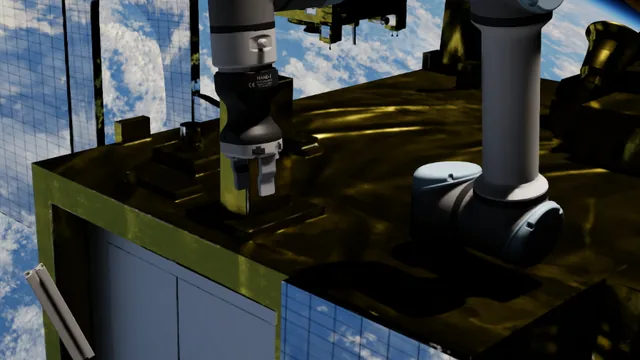
ICRA 2025 Workshop on Enhancing Dexterity in Space Environments
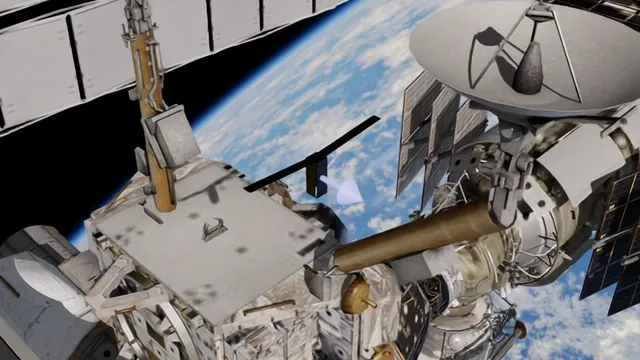
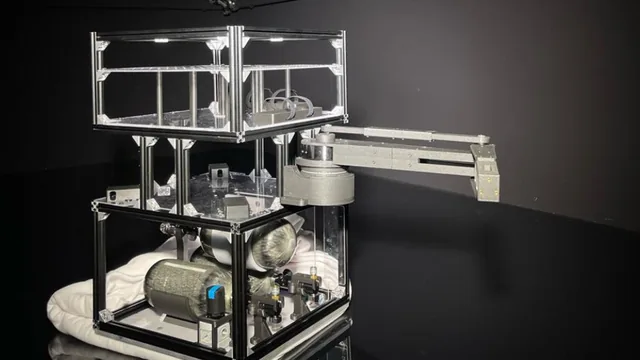
SnT Partnership Day 2025
Development, Verification & Validation of AI-based GNC for Space Operations
2024 5 publications
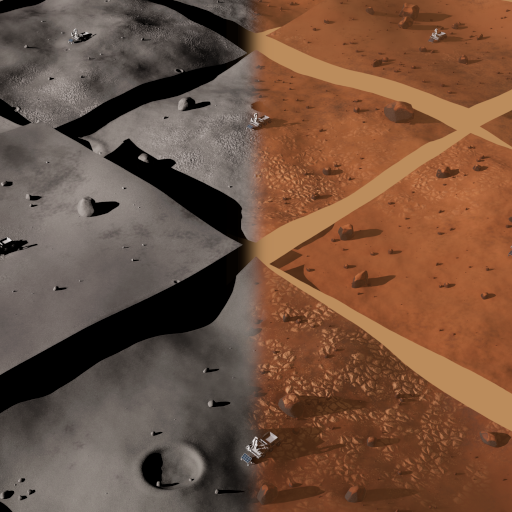
CoRL 2024 Workshop on Mastering Robot Manipulation in a World of Abundant Data
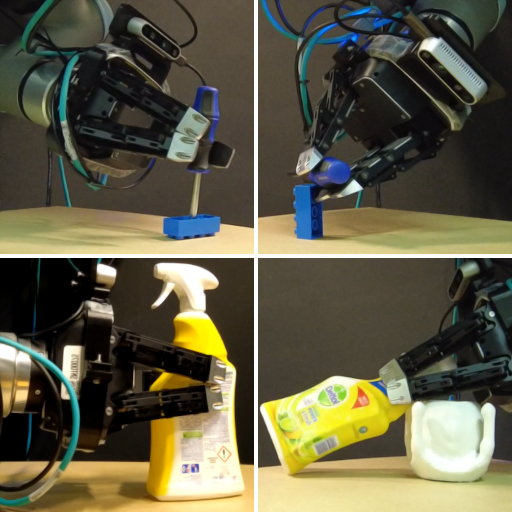
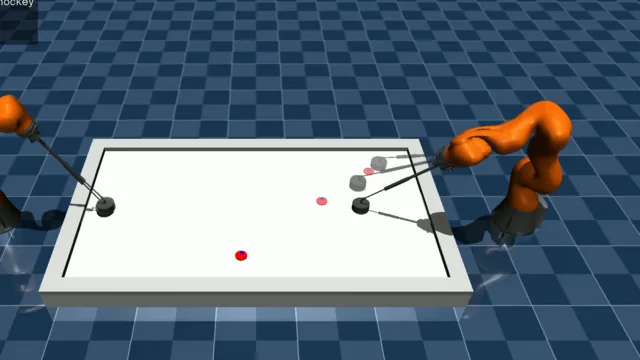
NeurIPS 2024 Datasets and Benchmarks Track
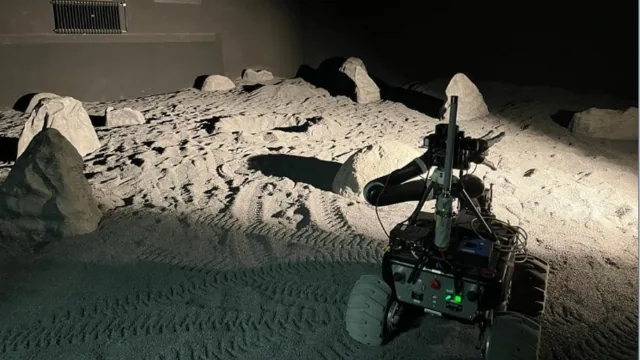
VR 2024 Abstracts and Workshops
Immersive Rover Control and Obstacle Detection based on Extended Reality and Artificial Intelligence
2023 1 publication
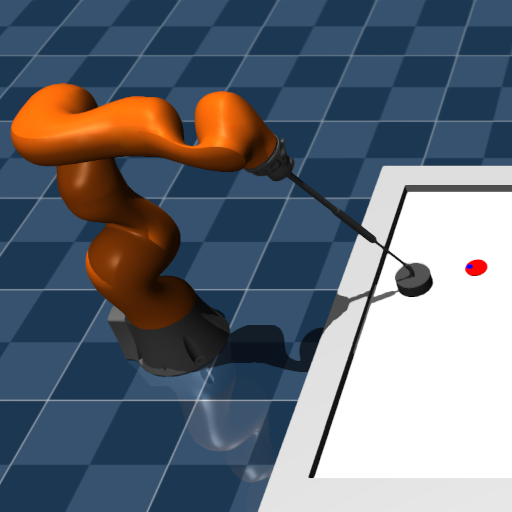
NeurIPS 2023 Robot Air Hockey Challenge
Learning to Play Air Hockey with Model-Based Deep Reinforcement Learning
2022 1 publication
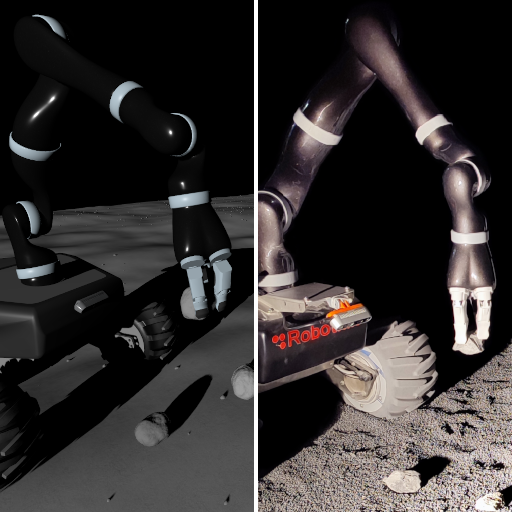
2021 1 publication
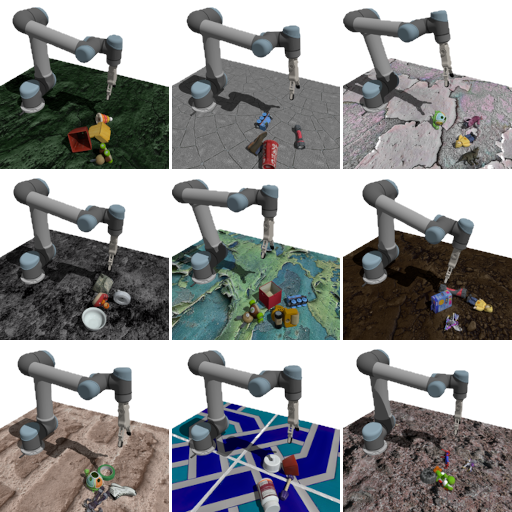
Master's Thesis Aalborg University
Deep Reinforcement Learning for Robotic Grasping from Octrees