Teaching
Robotic Manipulation in Space
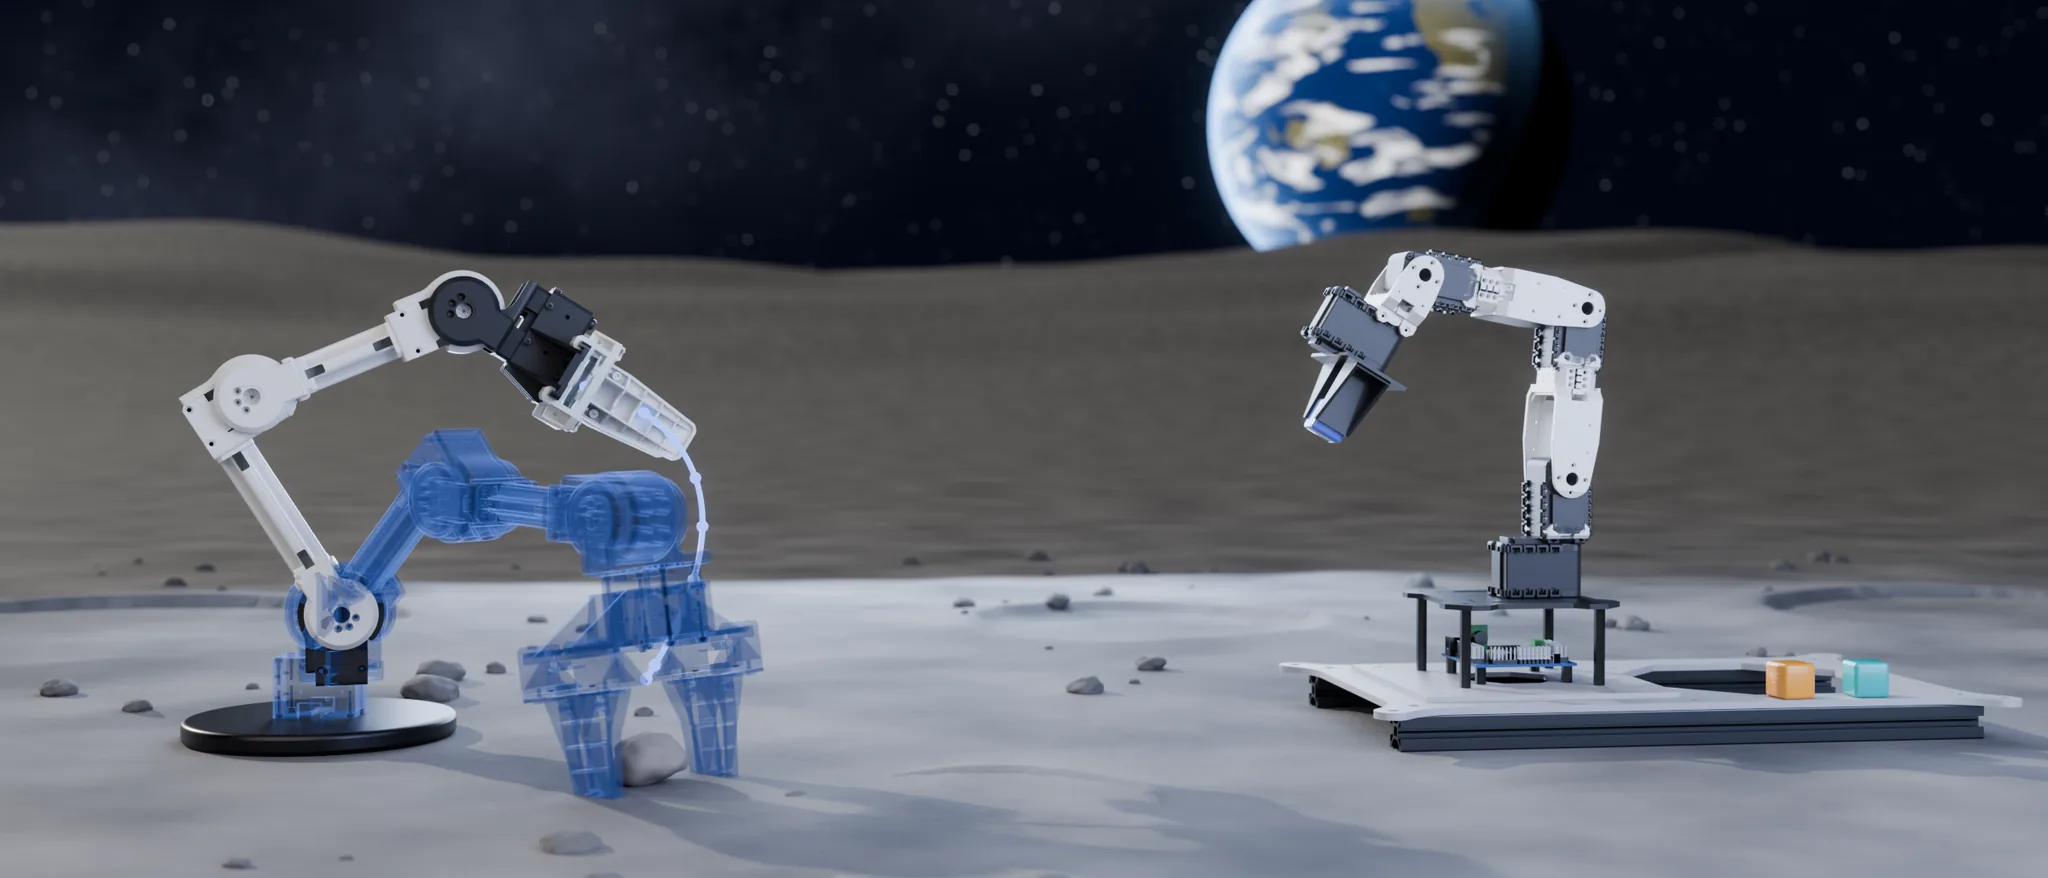
I prepare and teach the hands-on labs for third-semester students of the Master in Space Technologies and Business (formerly the Interdisciplinary Space Master). Students program real robot arms, in simulation and on hardware.
- Robot kinematics
- Motion planning
- Robot control
- Space applications
Lab code
Both labs drive MoveIt 2 from Python with my pymoveit2 library.