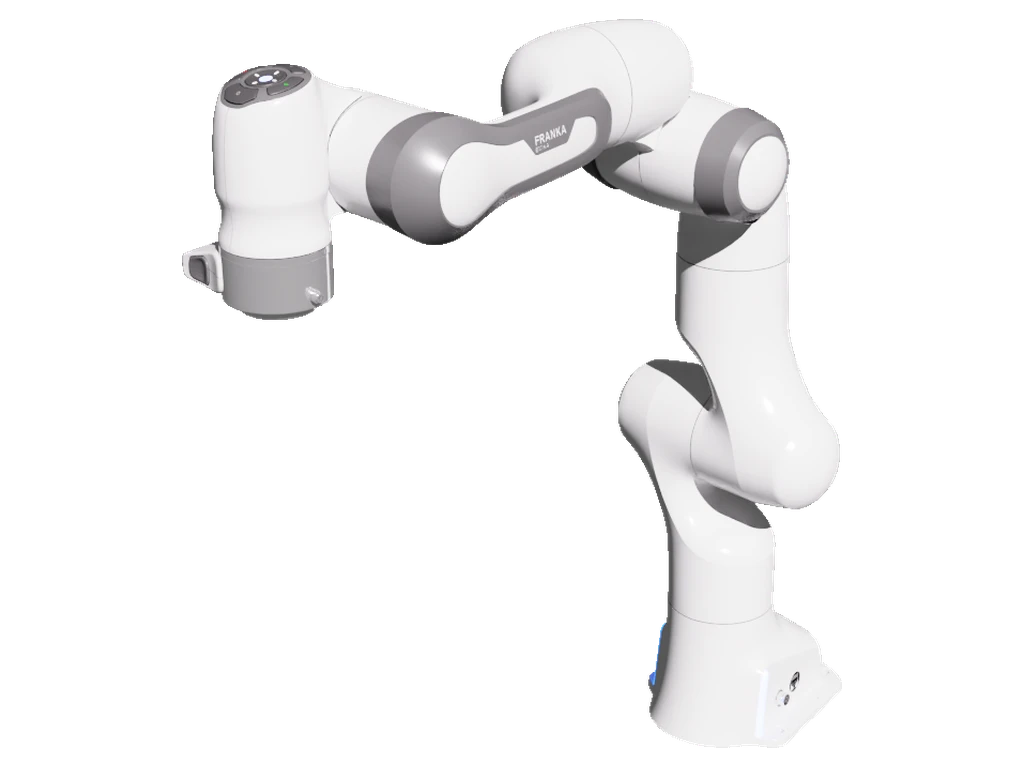
7-DoF torque-controlled research arm from Franka Robotics
| |
|---|
| DoF | 7 |
| End Effector | FrankaHand |
| Base Frame | panda_link0 |
| Flange Frame | panda_link7 |
| Sensors | 3 |
| Action Modes | 5 (default: diff_ik) |
| Source | SRB |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
osc_fixed | Operational Space Controller | 6 | pos=0.1, ori=0.1 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.1, ori=0.1, stiffness=120.0 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
joint_pos_rel | Relative Joint Position | 7 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| panda_shoulder | panda_joint[1-4] | 87 N·m | 2.175 rad/s | 4000 | 800 |
| panda_forearm | panda_joint[5-7] | 12 N·m | 2.61 rad/s | 4000 | 800 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | panda_link0/camera_base |
| cam_wrist | Camera | panda_link7/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| panda_joint1 | 0.0 rad |
| panda_joint2 | 0.0 rad |
| panda_joint3 | 0.0 rad |
| panda_joint4 | -1.570796 rad (-90 deg) |
| panda_joint5 | 0.0 rad |
| panda_joint6 | 1.570796 rad (90 deg) |
| panda_joint7 | 0.785398 rad (45 deg) |
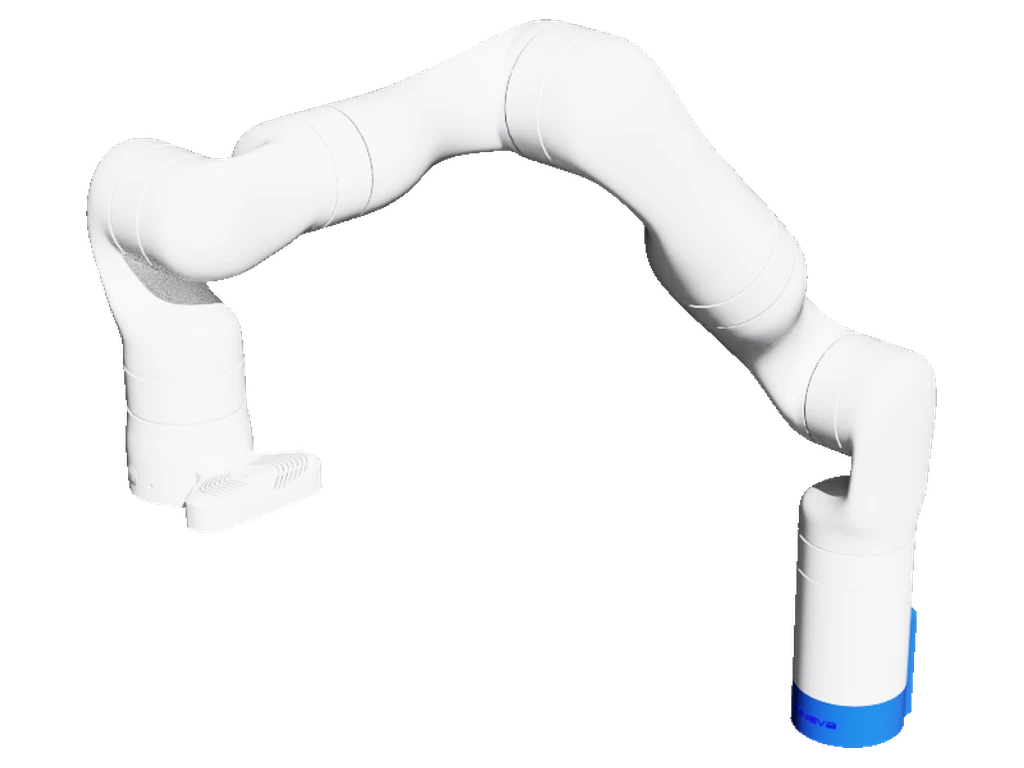
7-DoF lightweight research arm from Kinova Robotics
| |
|---|
| DoF | 7 |
| End Effector | None |
| Base Frame | base_link |
| Flange Frame | end_effector_link |
| Sensors | 3 |
| Action Modes | 6 (default: diff_ik) |
| Source | Isaac Lab |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
osc_fixed | Operational Space Controller | 6 | pos=0.1, ori=0.1 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.1, ori=0.1, stiffness=120.0 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
smooth_osc | Smooth Operational Space Controller | 6 | pos=0.1, ori=0.1 |
joint_pos_rel | Relative Joint Position | 7 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | joint_[1-7] | 2340 N·m | 10 rad/s | 500 | 200 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | base_link/camera_base |
| cam_wrist | Camera | end_effector_link/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| joint_1 | 0.0 rad |
| joint_2 | 0.785398 rad (45 deg) |
| joint_3 | 0.0 rad |
| joint_4 | 0.785398 rad (45 deg) |
| joint_5 | 0.0 rad |
| joint_6 | 1.570796 rad (90 deg) |
| joint_7 | 0.0 rad |
| |
|---|
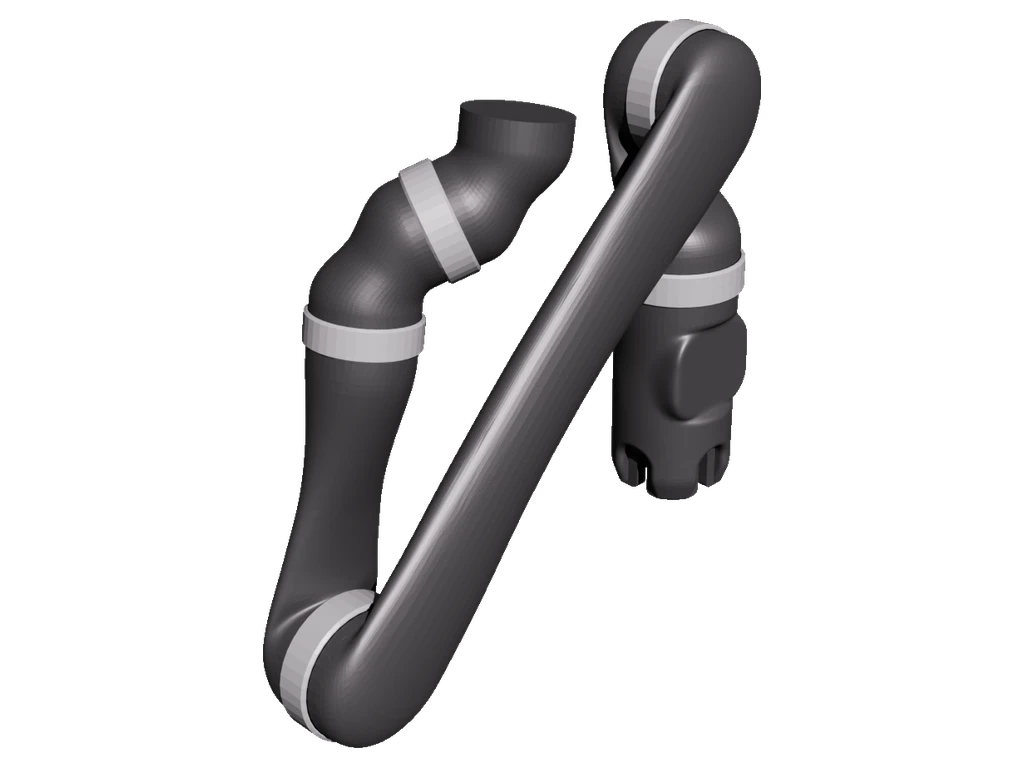
| DoF | 6 |
| End Effector | Kinova300 |
| Base Frame | j2n6s_link_base |
| Flange Frame | j2n6s_link_6 |
| Sensors | 3 |
| Action Modes | 2 (default: diff_ik) |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | j2n6s_joint_[1-6] | 80 N·m | 100 rad/s | 4000 | 1000 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | j2n6s_link_base/camera_base |
| cam_wrist | Camera | j2n6s_link_6/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| j2n6s_joint_1 | 0.0 rad |
| j2n6s_joint_2 | 2.617994 rad (150 deg) |
| j2n6s_joint_3 | 5.759587 rad (330 deg) |
| j2n6s_joint_4 | -1.570796 rad (-90 deg) |
| j2n6s_joint_5 | 0.0 rad |
| j2n6s_joint_6 | 0.0 rad |
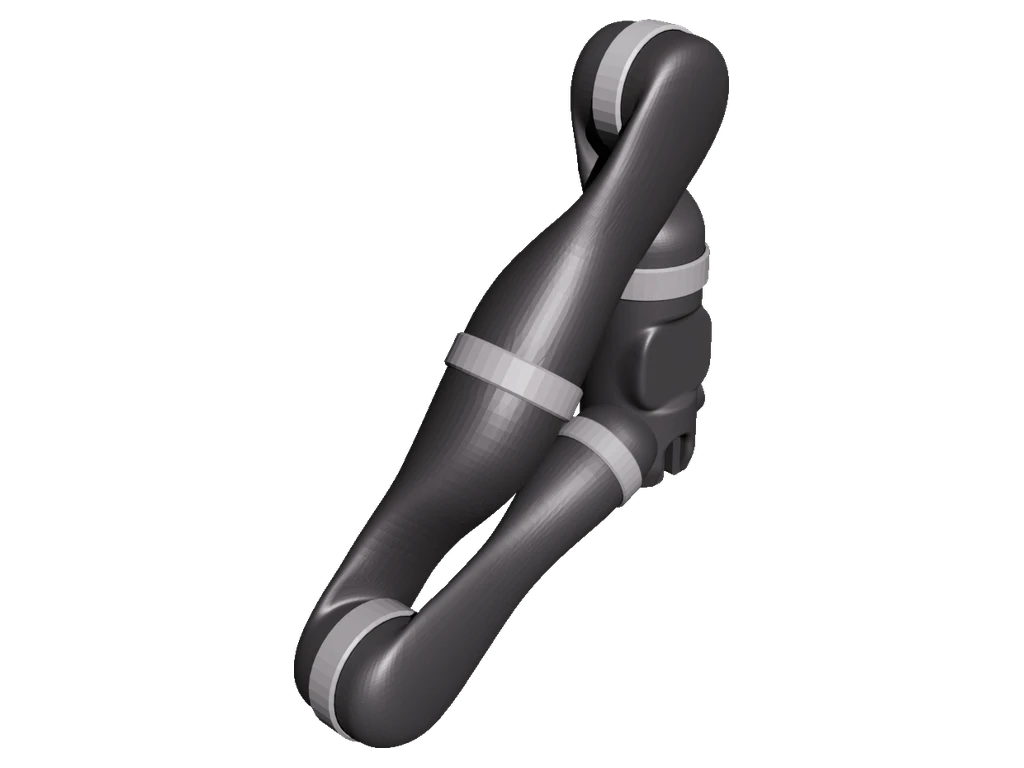
| |
|---|
| DoF | 7 |
| End Effector | Kinova300 |
| Base Frame | j2n7s_link_base |
| Flange Frame | j2n7s_link_7 |
| Sensors | 3 |
| Action Modes | 2 (default: diff_ik) |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
joint_pos_rel | Relative Joint Position | 7 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | j2n7s_joint_[1-7] | 80 N·m | 100 rad/s | 4000 | 1000 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | j2n7s_link_base/camera_base |
| cam_wrist | Camera | j2n7s_link_7/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| j2n7s_joint_1 | 0.0 rad |
| j2n7s_joint_2 | 2.617994 rad (150 deg) |
| j2n7s_joint_3 | 0.0 rad |
| j2n7s_joint_4 | 0.523599 rad (30 deg) |
| j2n7s_joint_5 | 1.570796 rad (90 deg) |
| j2n7s_joint_6 | 0.0 rad |
| j2n7s_joint_7 | 0.0 rad |
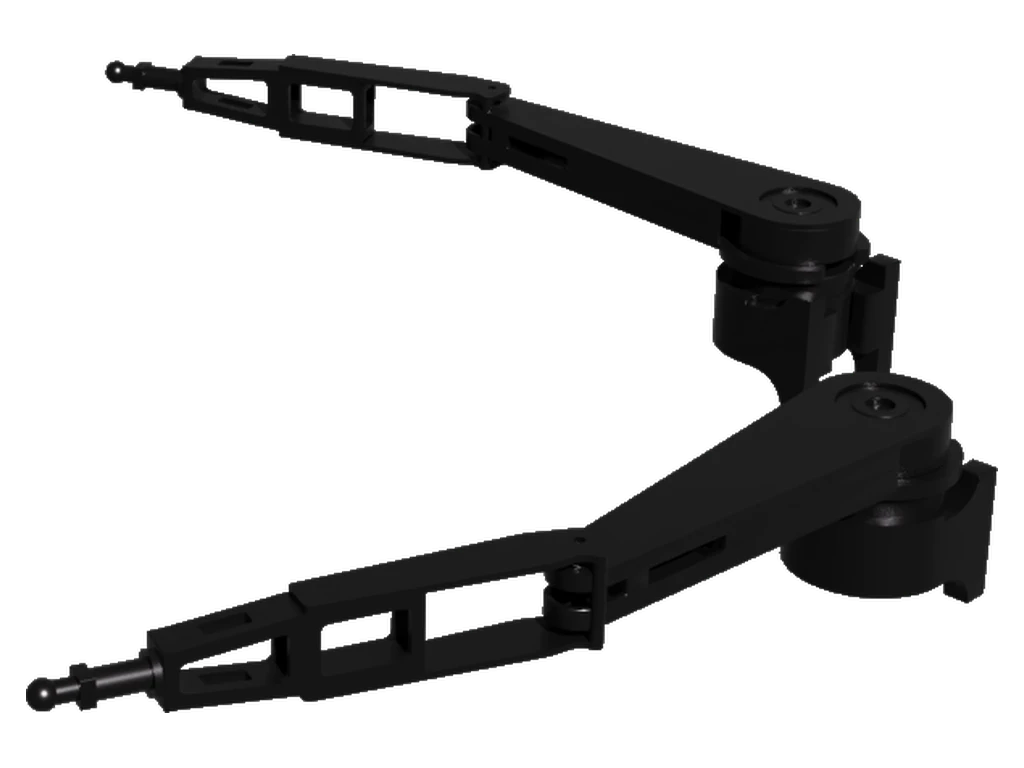
| |
|---|
| DoF | 4 |
| End Effector | None |
| Base Frame | base_link |
| Flange Frame | – |
| Sensors | 0 |
| Action Modes | default: dual_arm_joint_pos_abs |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
dual_arm_joint_pos_abs * | Joint Position To Limits | 4 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| left_arm | left_shoulder_joint, left_elbow_joint | 15 N·m | – | 400 | 80 |
| right_arm | right_shoulder_joint, right_elbow_joint | 15 N·m | – | 400 | 80 |
Initial Joint Configuration
| Joint | Position |
|---|
| right_elbow_joint | 0.4 rad (22.918312 deg) |
| left_elbow_joint | -0.4 rad (-22.918312 deg) |
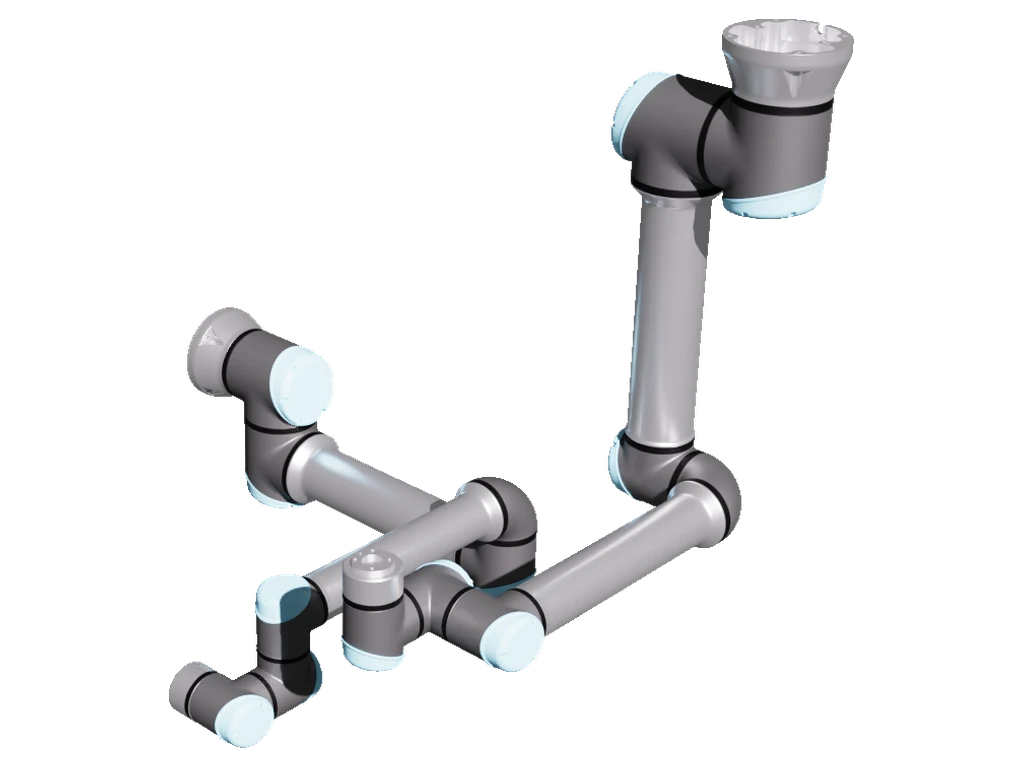
| |
|---|
| DoF | 7 |
| End Effector | None |
| Base Frame | _virtual_world |
| Flange Frame | – |
| Sensors | 0 |
| Action Modes | default: dual_arm_osc |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
dual_arm_osc * | Operational Space Controller | 24 | arm_ceiling: pos=0.1, ori=0.1, stiffness=120.0, arm_wall: pos=0.1, ori=0.1, stiffness=120.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| rail | rail_joint | 400 N·m | 0.2 rad/s | 3000 | 2500 |
| arm | .*shoulder.*, .*elbow.*, .*wrist.* | 87 N·m | 100 rad/s | 800 | 40 |
Initial Joint Configuration
| Joint | Position |
|---|
| rail_joint | 2 rad (114.591559 deg) |
| shoulder_pan_joint | 0.0 rad |
| shoulder_lift_joint | -1.570796 rad (-90 deg) |
| elbow_joint | 1.570796 rad (90 deg) |
| wrist_1_joint | -1.570796 rad (-90 deg) |
| wrist_2_joint | -1.570796 rad (-90 deg) |
| wrist_3_joint | -1.570796 rad (-90 deg) |
5-DoF low-cost open-source motor-driven arm
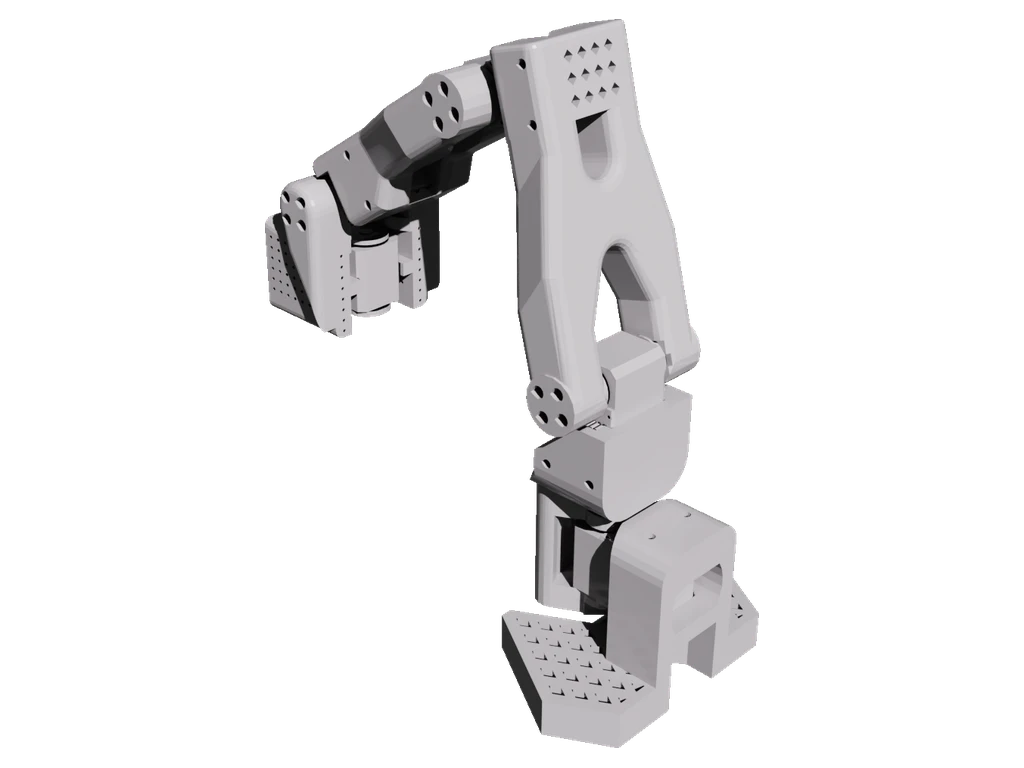
| |
|---|
| DoF | 5 |
| End Effector | SOArm100Gripper |
| Base Frame | Base |
| Flange Frame | Fixed_Gripper |
| Sensors | 3 |
| Action Modes | 3 (default: diff_ik) |
| Source | SRB |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.05 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.05, ori=0.05, stiffness=120.0 |
joint_pos_rel | Relative Joint Position | 5 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 10 N·m | 10 rad/s | 100 | 20 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | Base/camera_base |
| cam_wrist | Camera | Fixed_Gripper/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| Shoulder_Rotation | 0.0 rad |
| Shoulder_Pitch | -0.261799 rad (-15 deg) |
| Elbow | 0.349066 rad (20 deg) |
| Wrist_Pitch | 0.087266 rad (5 deg) |
| Wrist_Roll | 0.0 rad |
7-DoF low-cost open-source motor-driven arm
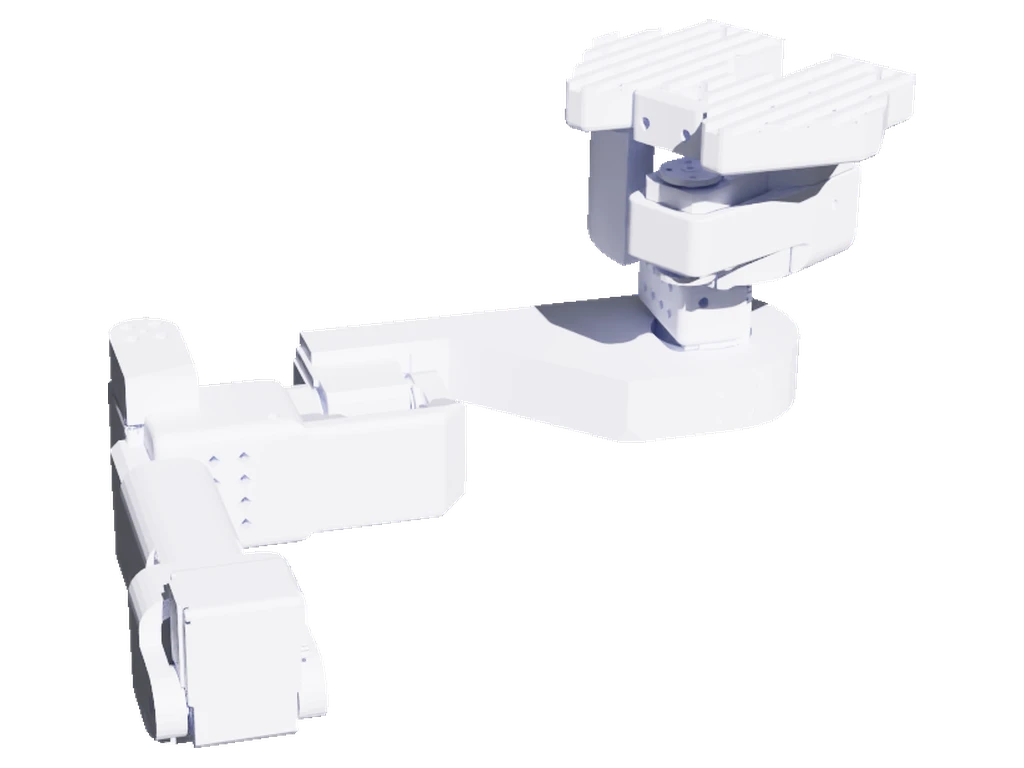
| |
|---|
| DoF | 7 |
| End Effector | None |
| Base Frame | Base |
| Flange Frame | End_Servo |
| Sensors | 3 |
| Action Modes | 2 (default: diff_ik) |
| Source | SRB |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.05 |
joint_pos_rel | Relative Joint Position | 7 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 10 N·m | 10 rad/s | 100 | 20 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | Base/camera_base |
| cam_wrist | Camera | End_Servo/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| Shoulder_Pitch | 2.094395 rad (120 deg) |
| Shoulder_Yaw | 0.0 rad |
| Humeral_Rotation | 0.0 rad |
| Elbow | -1.570796 rad (-90 deg) |
| Wrist_Roll | 0.0 rad |
| Wrist_Yaw | 0.0 rad |
| Wrist_Pitch | -1.570796 rad (-90 deg) |
Large-scale space manipulator for the Lunar Gateway station
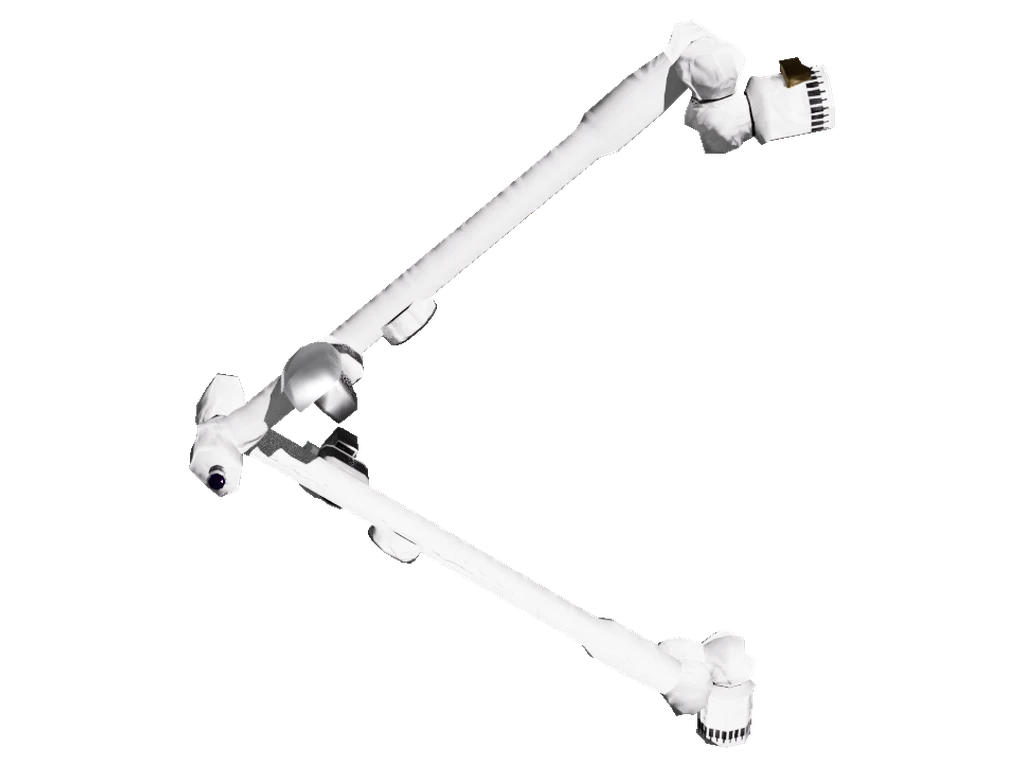
| |
|---|
| DoF | 7 |
| End Effector | None |
| Base Frame | canadarm3_large_0 |
| Flange Frame | canadarm3_large_7 |
| Sensors | 3 |
| Action Modes | 2 (default: diff_ik) |
| Source | SRB |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
joint_pos_rel | Relative Joint Position | 7 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| joints | canadarm3_large_joint_[1-7] | 2500 N·m | 5 rad/s | 40000 | 25000 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | canadarm3_large_0/camera_base |
| cam_wrist | Camera | canadarm3_large_7/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| canadarm3_large_joint_1 | 0.872665 rad (50 deg) |
| canadarm3_large_joint_2 | 0.0 rad |
| canadarm3_large_joint_3 | 0.959931 rad (55 deg) |
| canadarm3_large_joint_4 | 1.308997 rad (75 deg) |
| canadarm3_large_joint_5 | -0.523599 rad (-30 deg) |
| canadarm3_large_joint_6 | 0.0 rad |
| canadarm3_large_joint_7 | 0.0 rad |
Space manipulator designed for planetary surface operations
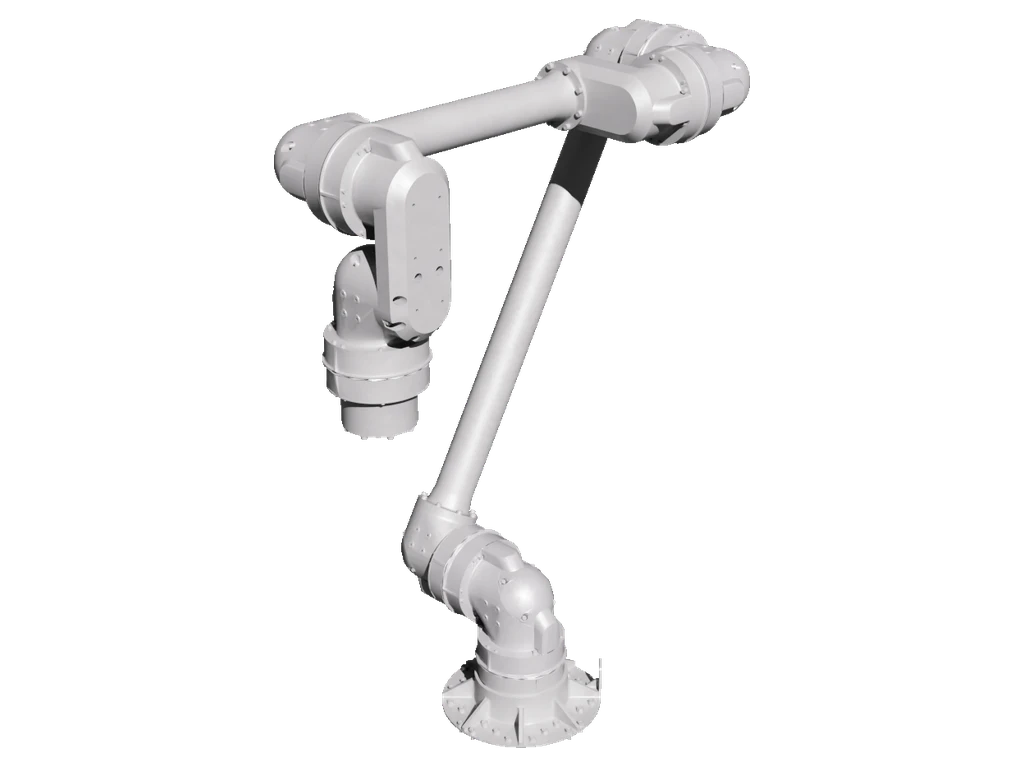
| |
|---|
| DoF | 6 |
| End Effector | None |
| Base Frame | link0 |
| Flange Frame | link6 |
| Sensors | 3 |
| Action Modes | 3 (default: diff_ik) |
| Source | SRB |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.05 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| joints | joint[1-6] | 500 N·m | 5 rad/s | 2500 | 500 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | link0/camera_base |
| cam_wrist | Camera | link6/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| joint1 | 0.0 rad |
| joint2 | -0.523599 rad (-30 deg) |
| joint3 | 2.094395 rad (120 deg) |
| joint4 | 0.0 rad |
| joint5 | 1.570796 rad (90 deg) |
| joint6 | 0.0 rad |
Compact lightweight arm from Unitree Robotics
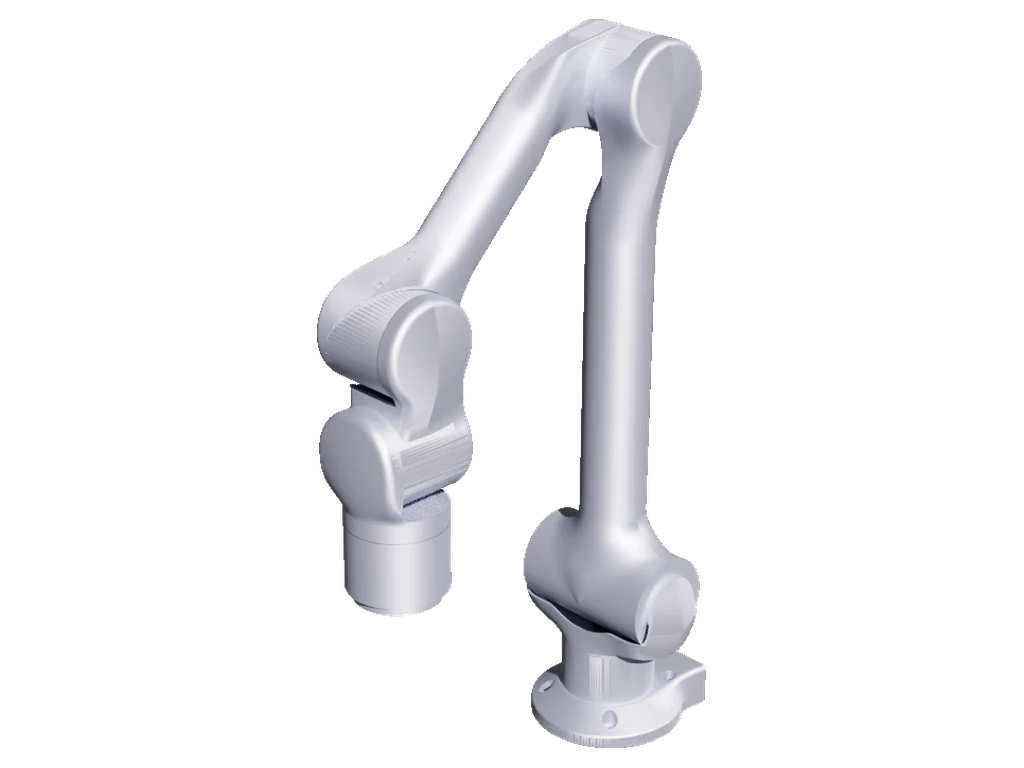
| |
|---|
| DoF | 6 |
| End Effector | None |
| Base Frame | link00 |
| Flange Frame | link06 |
| Sensors | 3 |
| Action Modes | 2 (default: diff_ik) |
| Source | SRB |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.05 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 87 N·m | 100 rad/s | 800 | 40 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | link00/camera_base |
| cam_wrist | Camera | link06/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| joint1 | 0.0 rad |
| joint2 | 1.570796 rad (90 deg) |
| joint3 | -0.785398 rad (-45 deg) |
| joint4 | 0.785398 rad (45 deg) |
| joint5 | 0.0 rad |
| joint6 | 0.0 rad |
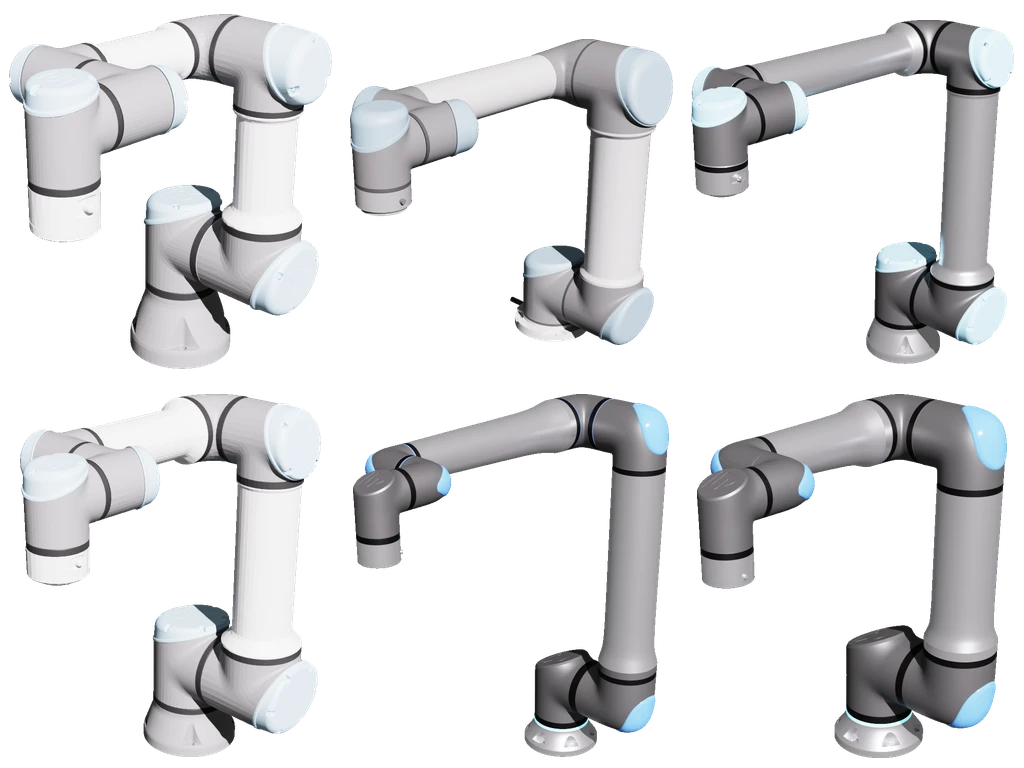
| |
|---|
| DoF | 6 |
| End Effector | None |
| Base Frame | base_link |
| Flange Frame | wrist_3_link |
| Sensors | 3 |
| Action Modes | 5 (default: diff_ik) |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
osc_fixed | Operational Space Controller | 6 | pos=0.1, ori=0.1 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.1, ori=0.1, stiffness=120.0 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 87 N·m | 100 rad/s | 800 | 40 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | base_link/camera_base |
| cam_wrist | Camera | wrist_3_link/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| shoulder_pan_joint | 0.0 rad |
| shoulder_lift_joint | -1.570796 rad (-90 deg) |
| elbow_joint | 1.570796 rad (90 deg) |
| wrist_1_joint | -1.570796 rad (-90 deg) |
| wrist_2_joint | -1.570796 rad (-90 deg) |
| wrist_3_joint | -1.570796 rad (-90 deg) |
Heavy-duty collaborative arm from Universal Robots
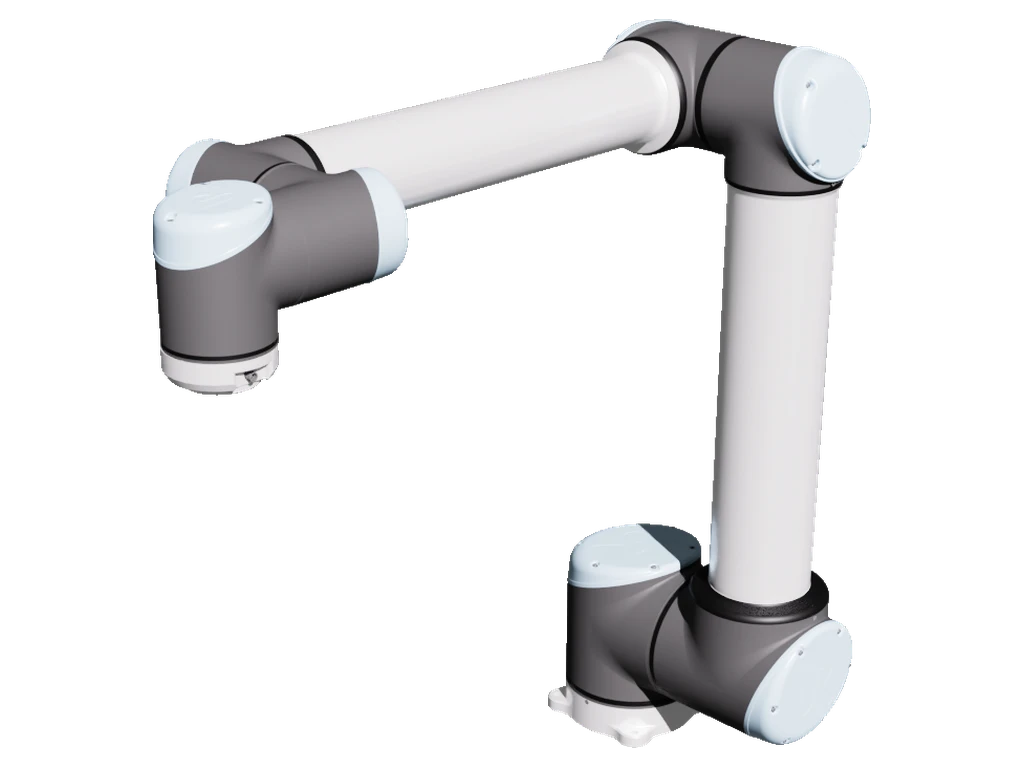
| |
|---|
| DoF | 6 |
| End Effector | None |
| Base Frame | base_link |
| Flange Frame | ee_link |
| Sensors | 3 |
| Action Modes | 5 (default: diff_ik) |
| Source | Isaac Lab |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
osc_fixed | Operational Space Controller | 6 | pos=0.1, ori=0.1 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.1, ori=0.1, stiffness=120.0 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 87 N·m | 100 rad/s | 800 | 40 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | base_link/camera_base |
| cam_wrist | Camera | ee_link/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| shoulder_pan_joint | 0.0 rad |
| shoulder_lift_joint | -1.570796 rad (-90 deg) |
| elbow_joint | 1.570796 rad (90 deg) |
| wrist_1_joint | -1.570796 rad (-90 deg) |
| wrist_2_joint | -1.570796 rad (-90 deg) |
| wrist_3_joint | -1.570796 rad (-90 deg) |
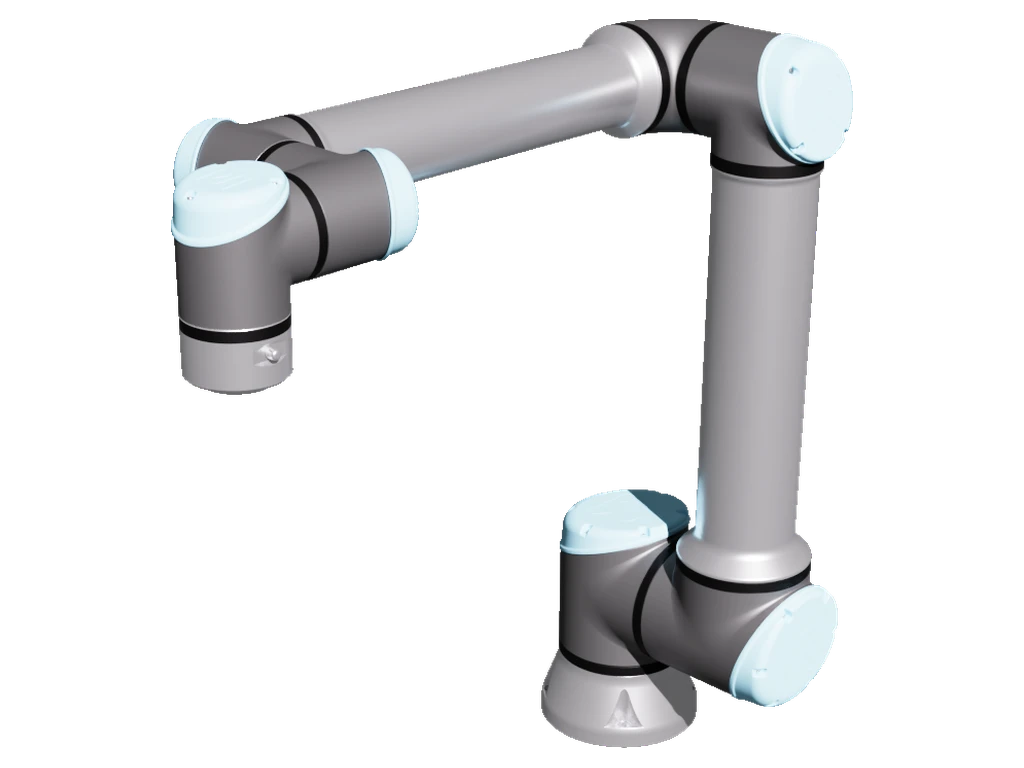
| |
|---|
| DoF | 6 |
| End Effector | None |
| Base Frame | base_link |
| Flange Frame | wrist_3_link |
| Sensors | 3 |
| Action Modes | 5 (default: diff_ik) |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
osc_fixed | Operational Space Controller | 6 | pos=0.1, ori=0.1 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.1, ori=0.1, stiffness=120.0 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 87 N·m | 100 rad/s | 800 | 40 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | base_link/camera_base |
| cam_wrist | Camera | wrist_3_link/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| shoulder_pan_joint | 0.0 rad |
| shoulder_lift_joint | -1.570796 rad (-90 deg) |
| elbow_joint | 1.570796 rad (90 deg) |
| wrist_1_joint | -1.570796 rad (-90 deg) |
| wrist_2_joint | -1.570796 rad (-90 deg) |
| wrist_3_joint | -1.570796 rad (-90 deg) |
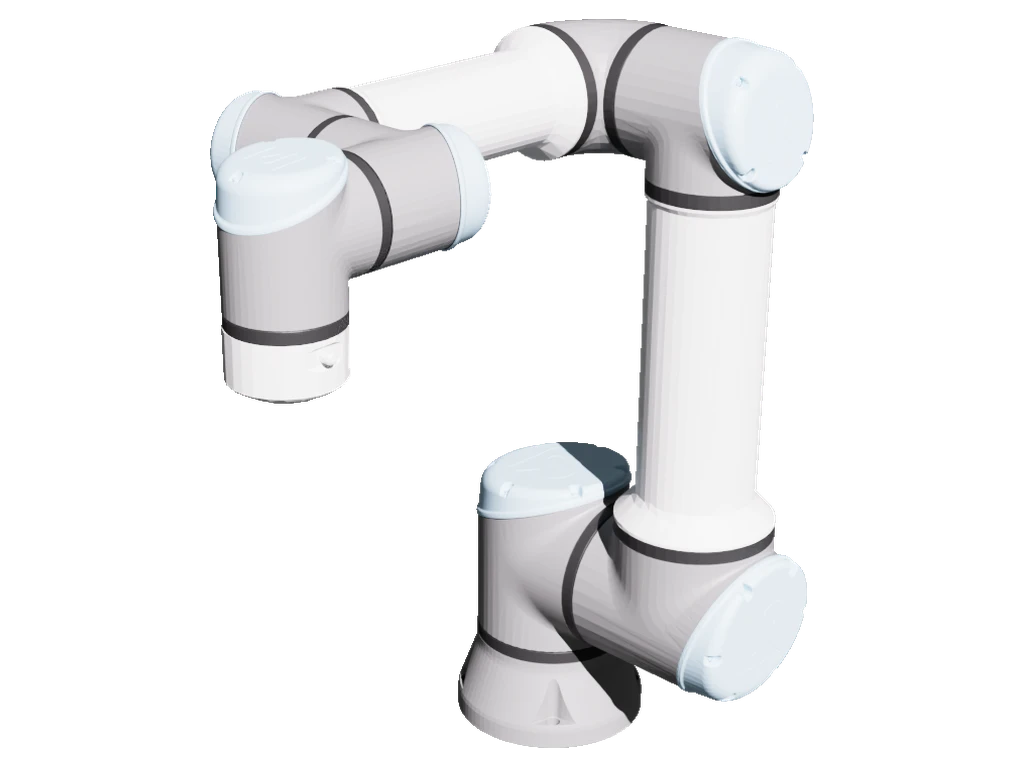
| |
|---|
| DoF | 6 |
| End Effector | None |
| Base Frame | base_link |
| Flange Frame | wrist_3_link |
| Sensors | 3 |
| Action Modes | 5 (default: diff_ik) |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
osc_fixed | Operational Space Controller | 6 | pos=0.1, ori=0.1 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.1, ori=0.1, stiffness=120.0 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 87 N·m | 100 rad/s | 800 | 40 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | base_link/camera_base |
| cam_wrist | Camera | wrist_3_link/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| shoulder_pan_joint | 0.0 rad |
| shoulder_lift_joint | -1.570796 rad (-90 deg) |
| elbow_joint | 1.570796 rad (90 deg) |
| wrist_1_joint | -1.570796 rad (-90 deg) |
| wrist_2_joint | -1.570796 rad (-90 deg) |
| wrist_3_joint | -1.570796 rad (-90 deg) |
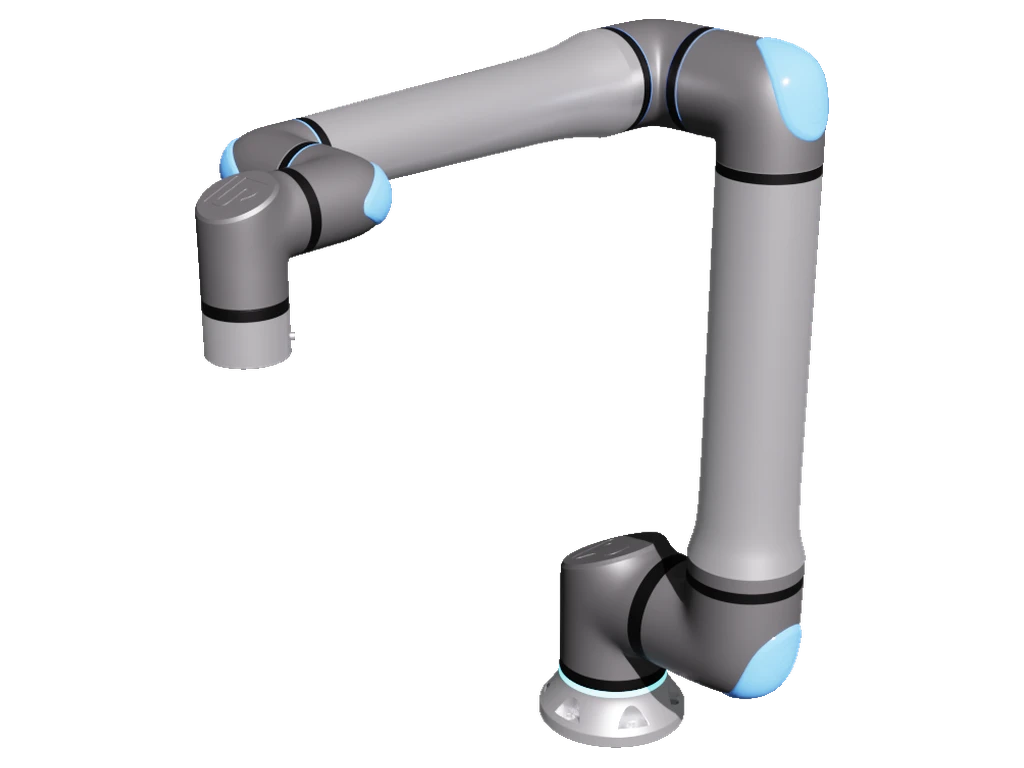
| |
|---|
| DoF | 6 |
| End Effector | None |
| Base Frame | base_link |
| Flange Frame | wrist_3_link |
| Sensors | 3 |
| Action Modes | 5 (default: diff_ik) |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
osc_fixed | Operational Space Controller | 6 | pos=0.1, ori=0.1 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.1, ori=0.1, stiffness=120.0 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 87 N·m | 100 rad/s | 800 | 40 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | base_link/camera_base |
| cam_wrist | Camera | wrist_3_link/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| shoulder_pan_joint | 0.0 rad |
| shoulder_lift_joint | -1.570796 rad (-90 deg) |
| elbow_joint | 1.570796 rad (90 deg) |
| wrist_1_joint | -1.570796 rad (-90 deg) |
| wrist_2_joint | -1.570796 rad (-90 deg) |
| wrist_3_joint | -1.570796 rad (-90 deg) |
Compact collaborative robot arm from Universal Robots
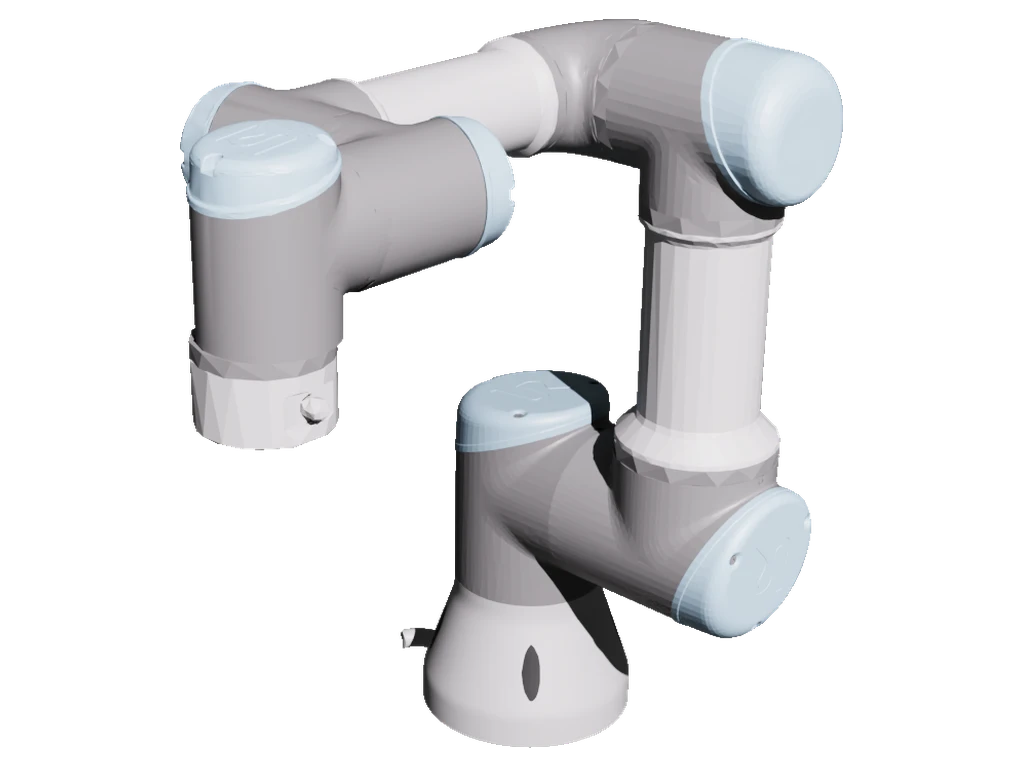
| |
|---|
| DoF | 6 |
| End Effector | None |
| Base Frame | base_link |
| Flange Frame | wrist_3_link |
| Sensors | 3 |
| Action Modes | 5 (default: diff_ik) |
| Source | Isaac Lab |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
osc_fixed | Operational Space Controller | 6 | pos=0.1, ori=0.1 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.1, ori=0.1, stiffness=120.0 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 87 N·m | 100 rad/s | 800 | 40 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | base_link/camera_base |
| cam_wrist | Camera | wrist_3_link/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| shoulder_pan_joint | 0.0 rad |
| shoulder_lift_joint | -1.570796 rad (-90 deg) |
| elbow_joint | 1.570796 rad (90 deg) |
| wrist_1_joint | -1.570796 rad (-90 deg) |
| wrist_2_joint | -1.570796 rad (-90 deg) |
| wrist_3_joint | -1.570796 rad (-90 deg) |
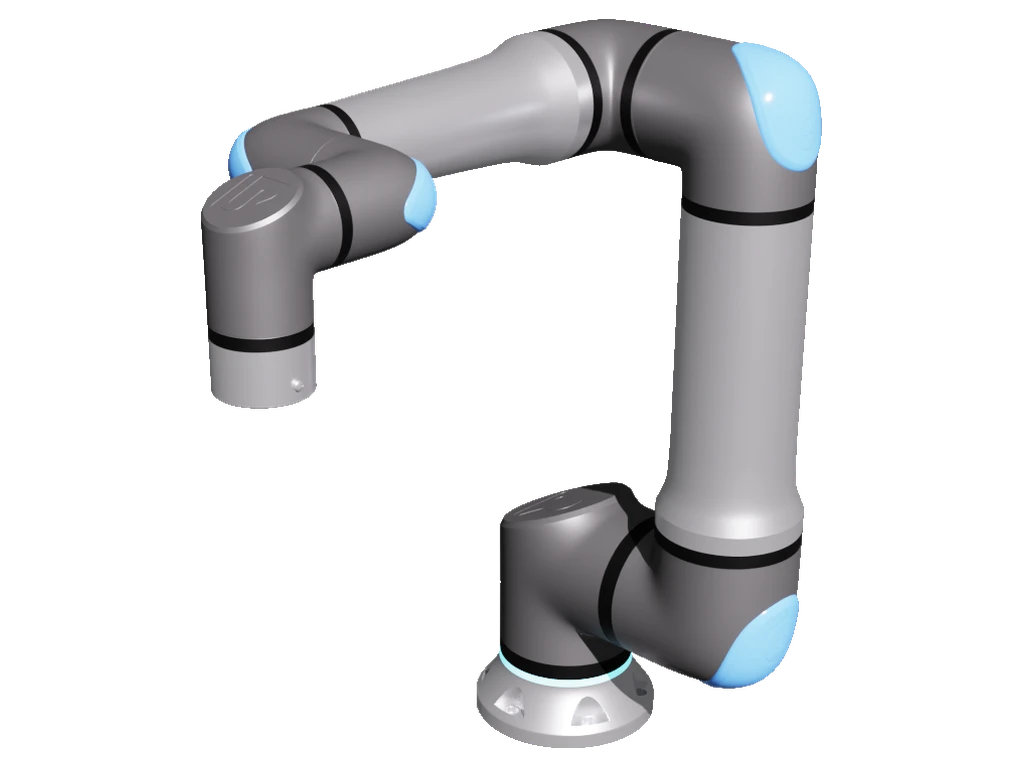
| |
|---|
| DoF | 6 |
| End Effector | None |
| Base Frame | base_link |
| Flange Frame | wrist_3_link |
| Sensors | 3 |
| Action Modes | 5 (default: diff_ik) |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
osc_fixed | Operational Space Controller | 6 | pos=0.1, ori=0.1 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.1, ori=0.1, stiffness=120.0 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 87 N·m | 100 rad/s | 800 | 40 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | base_link/camera_base |
| cam_wrist | Camera | wrist_3_link/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| shoulder_pan_joint | 0.0 rad |
| shoulder_lift_joint | -1.570796 rad (-90 deg) |
| elbow_joint | 1.570796 rad (90 deg) |
| wrist_1_joint | -1.570796 rad (-90 deg) |
| wrist_2_joint | -1.570796 rad (-90 deg) |
| wrist_3_joint | -1.570796 rad (-90 deg) |
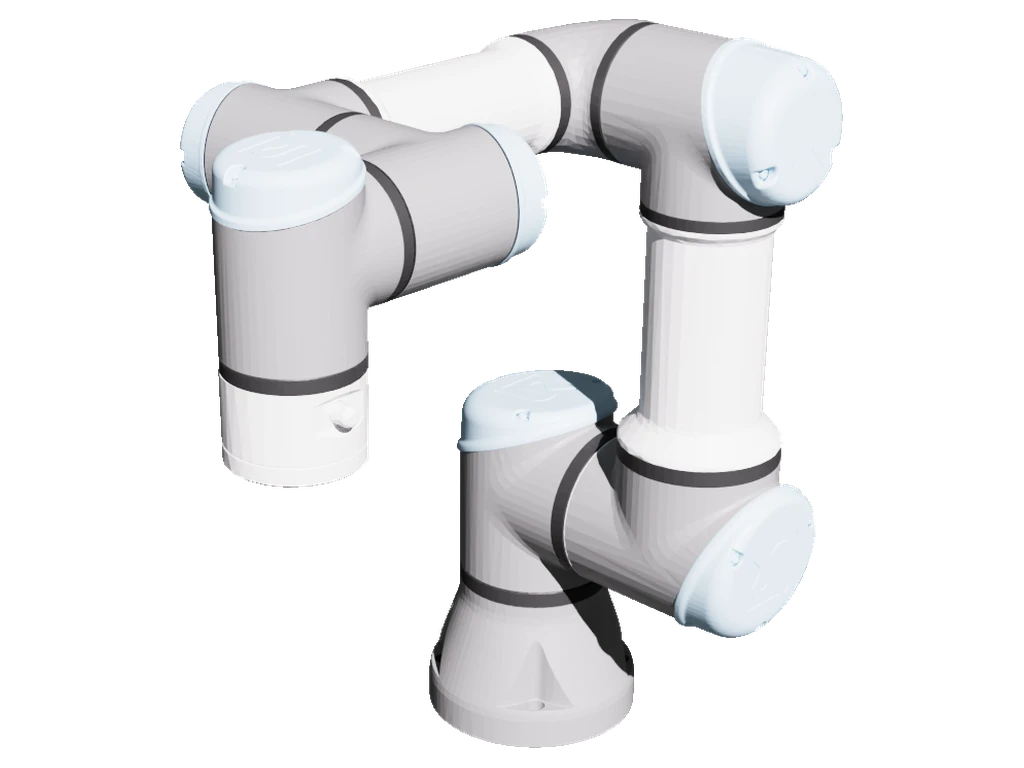
| |
|---|
| DoF | 6 |
| End Effector | None |
| Base Frame | base_link |
| Flange Frame | wrist_3_link |
| Sensors | 3 |
| Action Modes | 5 (default: diff_ik) |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
osc_fixed | Operational Space Controller | 6 | pos=0.1, ori=0.1 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.1, ori=0.1, stiffness=120.0 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 87 N·m | 100 rad/s | 800 | 40 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | base_link/camera_base |
| cam_wrist | Camera | wrist_3_link/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| shoulder_pan_joint | 0.0 rad |
| shoulder_lift_joint | -1.570796 rad (-90 deg) |
| elbow_joint | 1.570796 rad (90 deg) |
| wrist_1_joint | -1.570796 rad (-90 deg) |
| wrist_2_joint | -1.570796 rad (-90 deg) |
| wrist_3_joint | -1.570796 rad (-90 deg) |
Versatile mid-range collaborative arm from Universal Robots
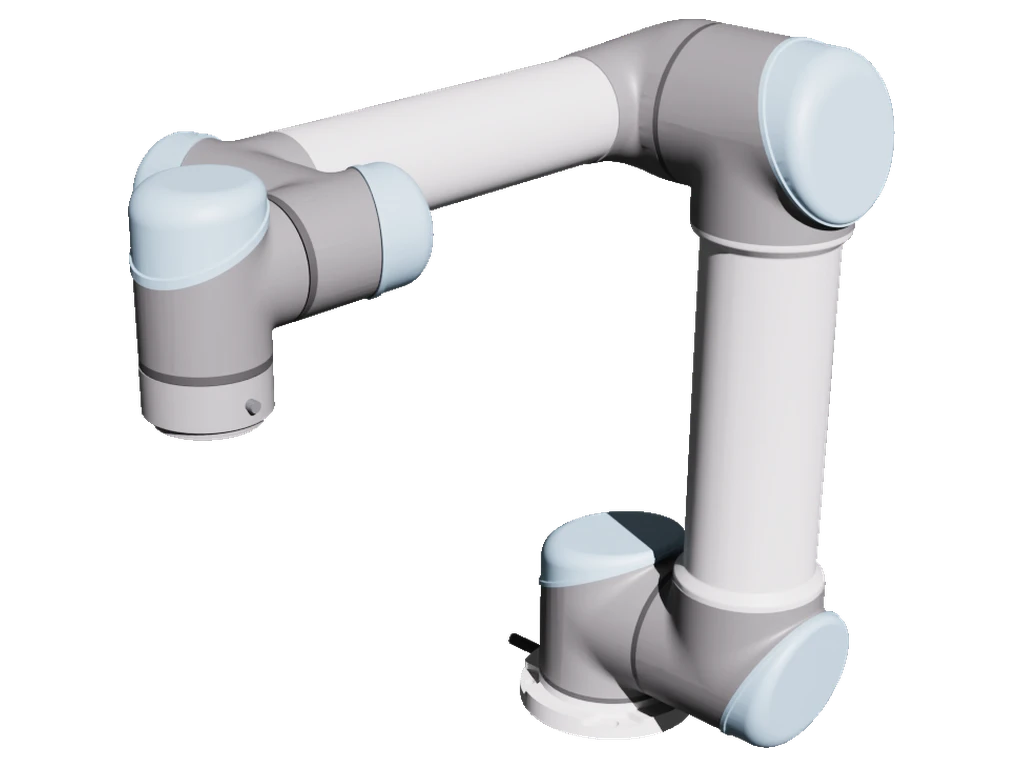
| |
|---|
| DoF | 6 |
| End Effector | None |
| Base Frame | base_link |
| Flange Frame | wrist_3_link |
| Sensors | 3 |
| Action Modes | 5 (default: diff_ik) |
| Source | Isaac Lab |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
osc_fixed | Operational Space Controller | 6 | pos=0.1, ori=0.1 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.1, ori=0.1, stiffness=120.0 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 87 N·m | 100 rad/s | 800 | 40 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | base_link/camera_base |
| cam_wrist | Camera | wrist_3_link/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| shoulder_pan_joint | 0.0 rad |
| shoulder_lift_joint | -1.570796 rad (-90 deg) |
| elbow_joint | 1.570796 rad (90 deg) |
| wrist_1_joint | -1.570796 rad (-90 deg) |
| wrist_2_joint | -1.570796 rad (-90 deg) |
| wrist_3_joint | -1.570796 rad (-90 deg) |
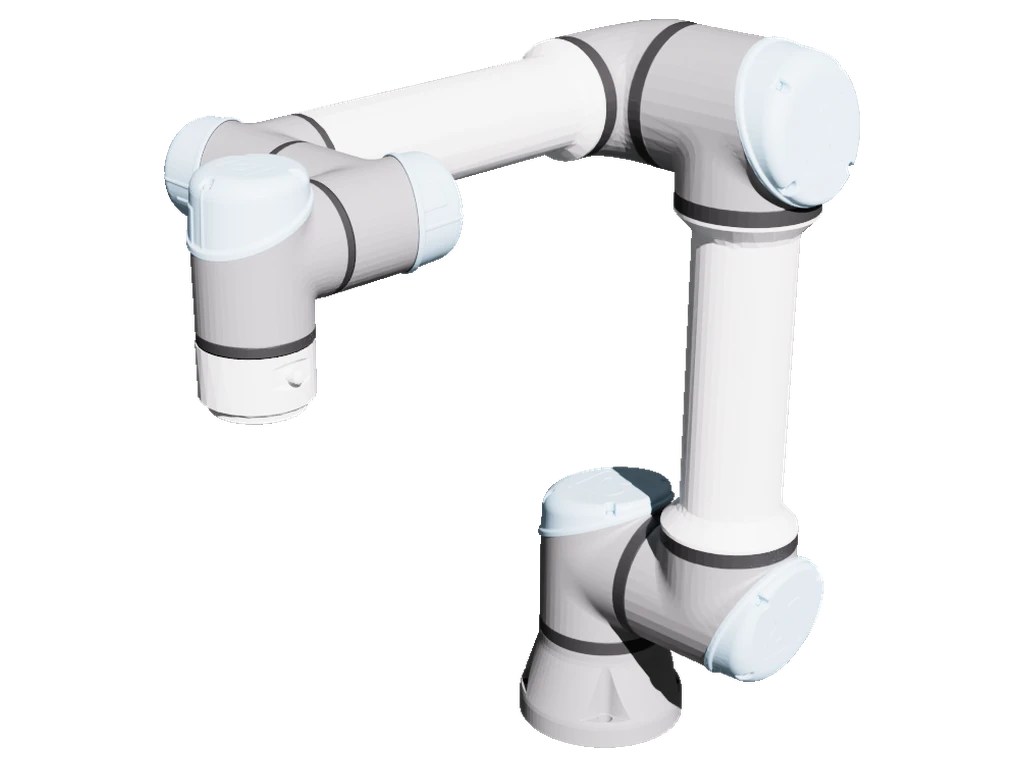
| |
|---|
| DoF | 6 |
| End Effector | None |
| Base Frame | base_link |
| Flange Frame | wrist_3_link |
| Sensors | 3 |
| Action Modes | 5 (default: diff_ik) |
Action Modes
| Mode | Controller | Dims | Scale |
|---|
diff_ik * | Differential Inverse Kinematics | 6 | 0.1 |
osc_fixed | Operational Space Controller | 6 | pos=0.1, ori=0.1 |
osc_var_stiffness | Operational Space Controller | 12 | pos=0.1, ori=0.1, stiffness=120.0 |
osc_var_full | Operational Space Controller | 18 | pos=0.1, ori=0.1, stiffness=120.0, damping=1.0 |
joint_pos_rel | Relative Joint Position | 6 | 1.0 |
Actuators
| Group | Joints | Effort | Velocity | Stiffness | Damping |
|---|
| arm | .* | 87 N·m | 100 rad/s | 800 | 40 |
Sensors
| Name | Type | Location |
|---|
| contacts_robot | Contact Sensor | .* |
| cam_base | Camera | base_link/camera_base |
| cam_wrist | Camera | wrist_3_link/camera_wrist |
Initial Joint Configuration
| Joint | Position |
|---|
| shoulder_pan_joint | 0.0 rad |
| shoulder_lift_joint | -1.570796 rad (-90 deg) |
| elbow_joint | 1.570796 rad (90 deg) |
| wrist_1_joint | -1.570796 rad (-90 deg) |
| wrist_2_joint | -1.570796 rad (-90 deg) |
| wrist_3_joint | -1.570796 rad (-90 deg) |