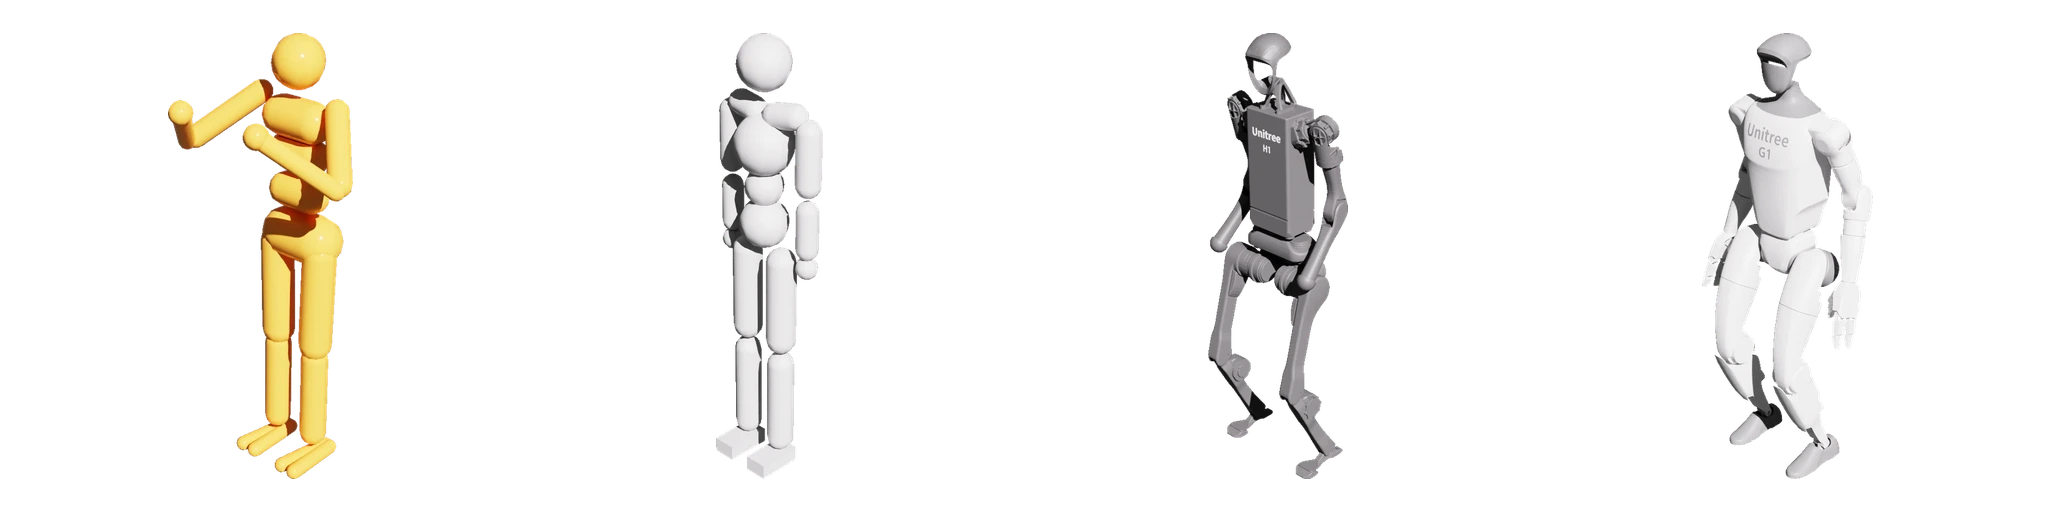
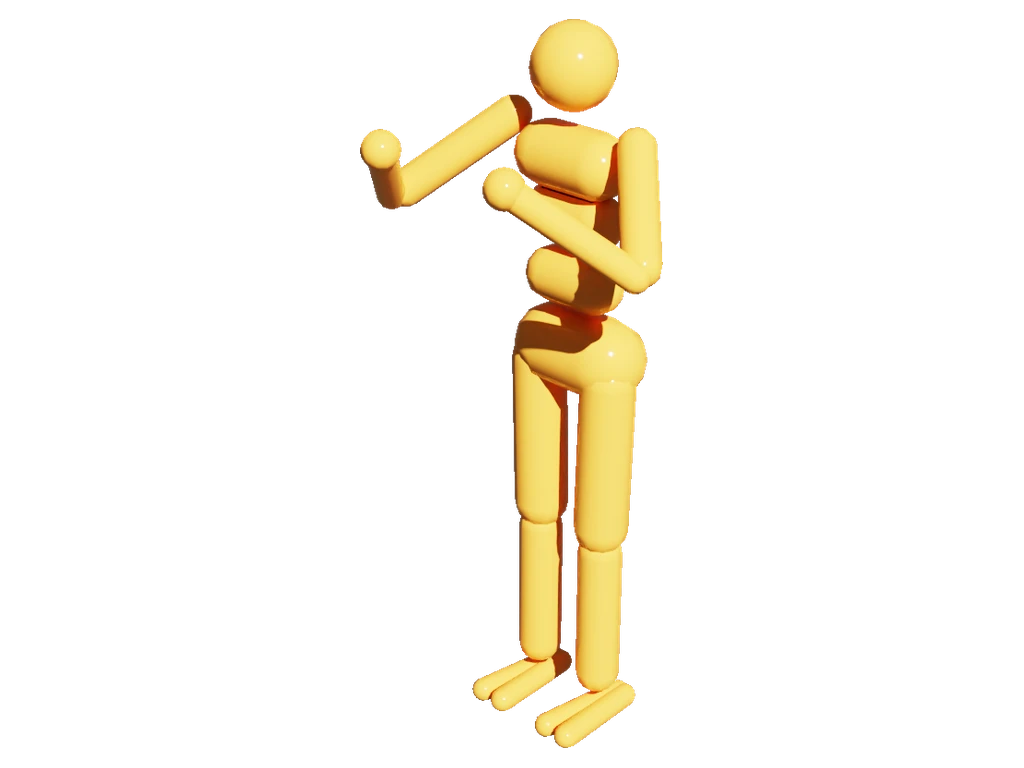
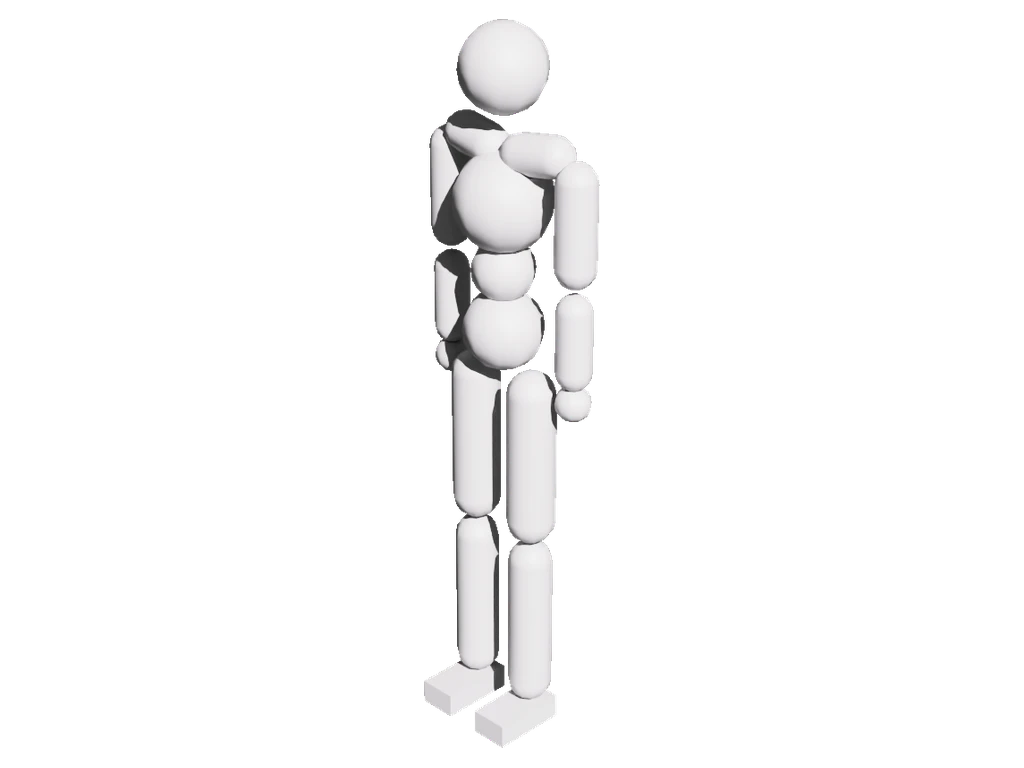
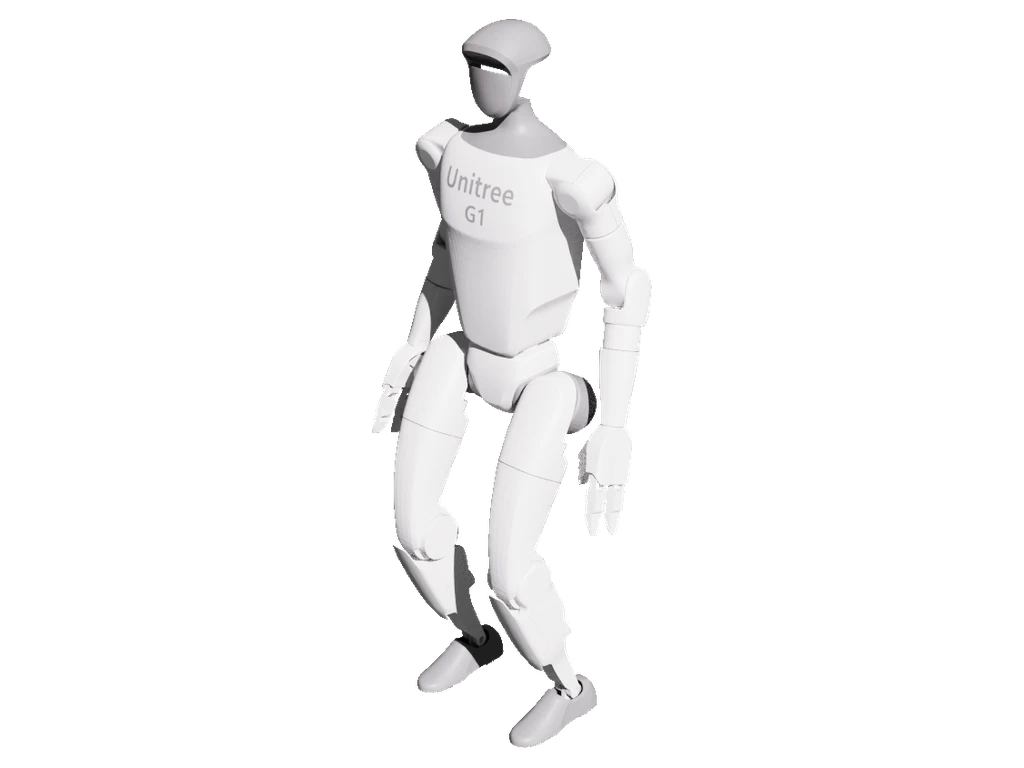
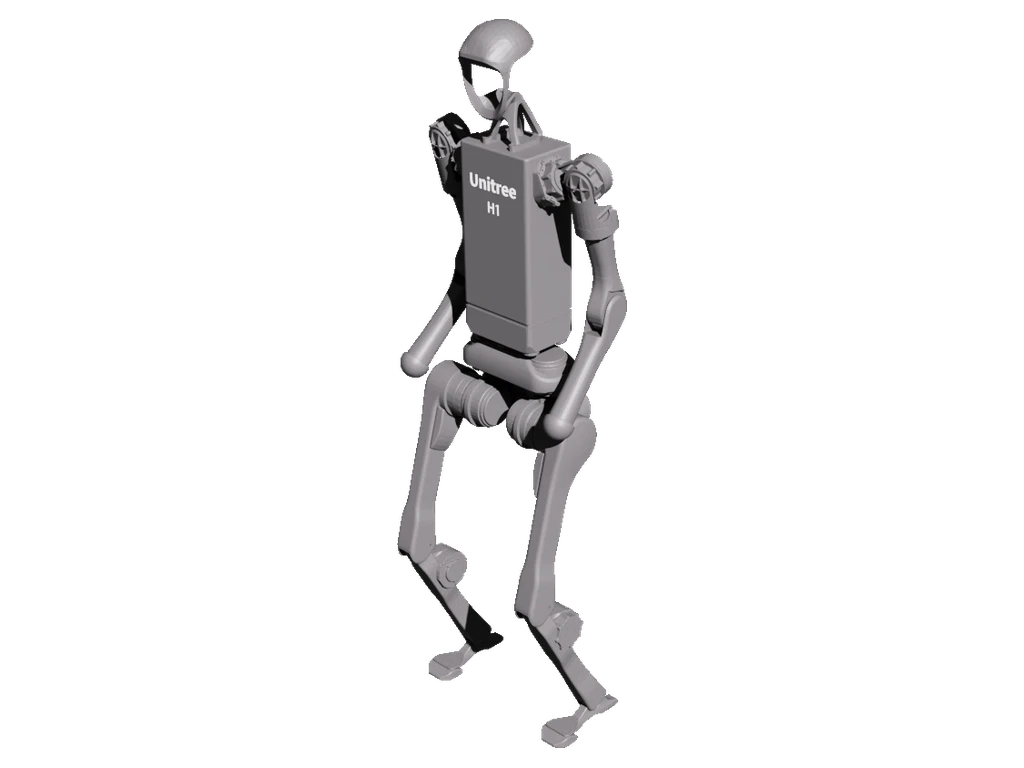
Mobile manipulators registered in the Space Robotics Bench: generic platforms that mount a manipulator on an aerial, ground, or orbital base, and humanoid robots. Generic platforms assemble their parts at runtime, so their listed DoF, sensors, and action modes cover only the class defaults; the composed robot inherits those of its parts.
DoF runtime-resolved End Effector None Sensors 0 Action Modes –
DoF runtime-resolved End Effector None Sensors 0 Action Modes –
DoF runtime-resolved End Effector None Sensors 0 Action Modes –
DoF runtime-resolved End Effector None Base Frame pelvisSensors 3 Action Modes default: joint_pos
Action Modes
Mode Controller Dims Scale
joint_pos *Joint Position To Limits runtime-resolved 1.0
Actuators
Group Joints Effort Velocity Stiffness Damping
body .*– – 2–20 0.1–5
Sensors
Name Type Location
imu_robot Imu pelviscontacts_feet Contact Sensor (left|right)_footcam_front Camera pelvis/camera_front
DoF runtime-resolved End Effector None Base Frame pelvisSensors 3 Action Modes default: joint_pos
Action Modes
Mode Controller Dims Scale
joint_pos *Joint Position To Limits runtime-resolved 1.0
Actuators
Group Joints Effort Velocity Stiffness Damping
body .*– – – –
Sensors
Name Type Location
imu_robot Imu pelviscontacts_feet Contact Sensor (left|right)_footcam_front Camera pelvis/camera_front
DoF runtime-resolved End Effector None Base Frame pelvisSensors 3 Action Modes default: joint_pos
Action Modes
Mode Controller Dims Scale
joint_pos *Joint Position To Limits runtime-resolved 1.0
Actuators
Group Joints Effort Velocity Stiffness Damping
legs .*_hip_yaw_joint, .*_hip_roll_joint, .*_hip_pitch_joint, .*_knee_joint, torso_joint300 N·m 100 rad/s 150–200 5 feet .*_ankle_pitch_joint, .*_ankle_roll_joint20 N·m – 20 2 arms .*_shoulder_pitch_joint, .*_shoulder_roll_joint, .*_shoulder_yaw_joint, .*_elbow_pitch_joint, .*_elbow_roll_joint, .*_five_joint, .*_three_joint, .*_six_joint, .*_four_joint, .*_zero_joint, .*_one_joint, .*_two_joint300 N·m 100 rad/s 40 10
Sensors
Name Type Location
imu_robot Imu pelviscontacts_feet Contact Sensor (left|right)_ankle_roll_linkcam_front Camera pelvis/camera_front
Initial Joint Configuration
Joint Position
.*_hip_pitch_joint-0.2 rad (-11.459156 deg) .*_knee_joint0.42 rad (24.064227 deg) .*_ankle_pitch_joint-0.23 rad (-13.178029 deg) .*_elbow_pitch_joint0.87 rad (49.847328 deg) left_shoulder_roll_joint 0.16 rad (9.167325 deg) left_shoulder_pitch_joint 0.35 rad (20.053523 deg) right_shoulder_roll_joint -0.16 rad (-9.167325 deg) right_shoulder_pitch_joint 0.35 rad (20.053523 deg) left_one_joint 1 rad (57.29578 deg) right_one_joint -1 rad (-57.29578 deg) left_two_joint 0.52 rad (29.793805 deg) right_two_joint -0.52 rad (-29.793805 deg)
The DoF and joint_pos action dimensions are runtime-resolved from the Unitree G1 USD articulation. The actuator configuration includes shoulder, elbow, ankle, and hand-like zero through six joint patterns.
DoF runtime-resolved End Effector None Base Frame pelvisSensors 3 Action Modes default: joint_pos
Action Modes
Mode Controller Dims Scale
joint_pos *Joint Position To Limits runtime-resolved 1.0
Actuators
Group Joints Effort Velocity Stiffness Damping
legs .*_hip_yaw, .*_hip_roll, .*_hip_pitch, .*_knee, torso300 N·m 100 rad/s 150–200 5 feet .*_ankle100 N·m 100 rad/s 20 4 arms .*_shoulder_pitch, .*_shoulder_roll, .*_shoulder_yaw, .*_elbow300 N·m 100 rad/s 40 10
Sensors
Name Type Location
imu_robot Imu pelviscontacts_feet Contact Sensor (left|right)_ankle_linkcam_front Camera pelvis/camera_front
Initial Joint Configuration
Joint Position
.*_hip_yaw0.0 rad .*_hip_roll0.0 rad .*_hip_pitch-0.28 rad (-16.042818 deg) .*_knee0.79 rad (45.263666 deg) .*_ankle-0.52 rad (-29.793805 deg) torso 0.0 rad .*_shoulder_pitch0.28 rad (16.042818 deg) .*_shoulder_roll0.0 rad .*_shoulder_yaw0.0 rad .*_elbow0.52 rad (29.793805 deg)