Environments – Digital Twins
Simulator environments model real-world facilities and testbeds; physical validation is not recorded.
Lunalab (lunalab)
Digital twin of the LunaLab planetary analogue testbed
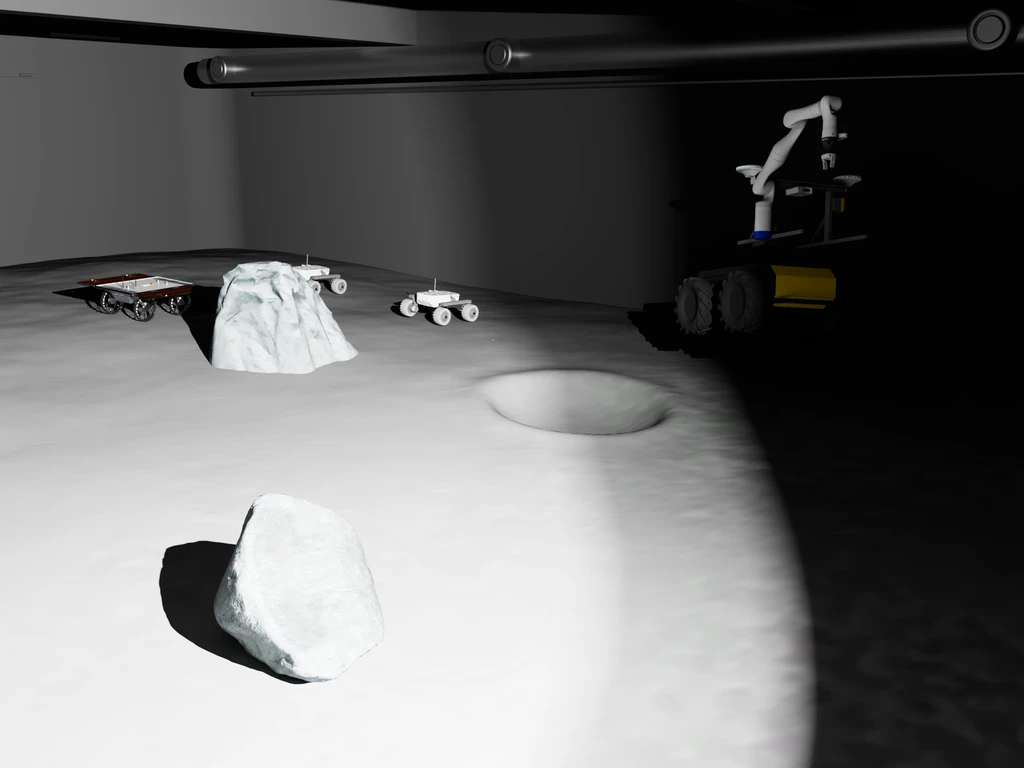
Readiness: simulator task implemented. Validation against the physical facility (geometry, lighting, sensor response) is not recorded in the capability ledger (
docs/data/capabilities.toml).
| Episode Length | 100000.0s (2500000 steps) |
| Reward Terms | 2 |
| Default Robot | Generic Ground Manipulator |
Compatible Robots
Reward Breakdown
| Term | Type | Weight | Scale | Notes |
|---|---|---|---|---|
| penalty_action_rate | Linear | -0.1 | – | |
| penalty_undesired_robot_contacts | Threshold | -0.5 | – |
Zerog Lab (zerog_lab)
Digital twin of a zero-gravity laboratory testbed
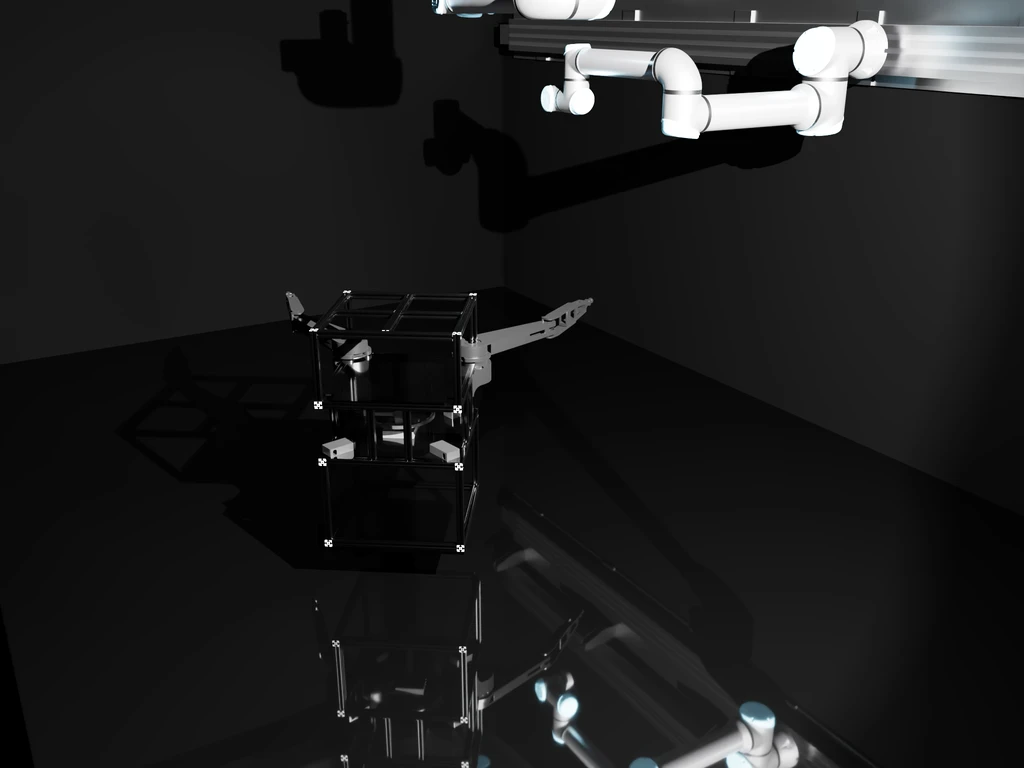
Readiness: simulator task implemented. Validation against the physical facility (geometry, lighting, sensor response) is not recorded in the capability ledger (
docs/data/capabilities.toml).
| Episode Length | 100000.0s (1000000 steps) |
| Reward Terms | 2 |
| Default Robot | Generic Orbital Manipulator |
Compatible Robots
Reward Breakdown
| Term | Type | Weight | Scale | Notes |
|---|---|---|---|---|
| penalty_action_rate | Linear | -0.1 | – | |
| penalty_fuel_consumption | Linear | -1 | – |